
Free 
Blank Man Go-Kart
MakerWorld
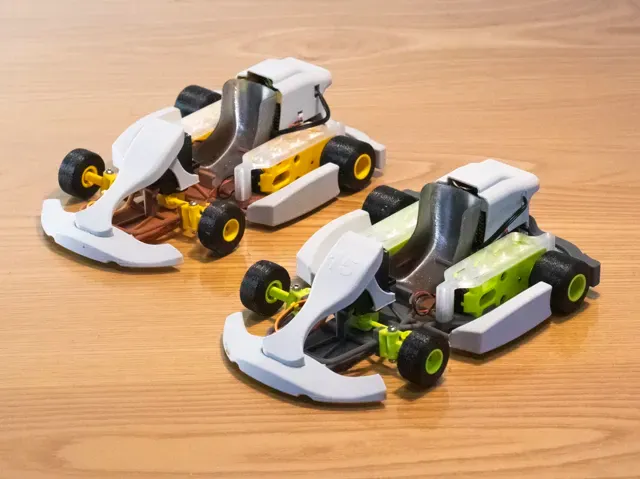
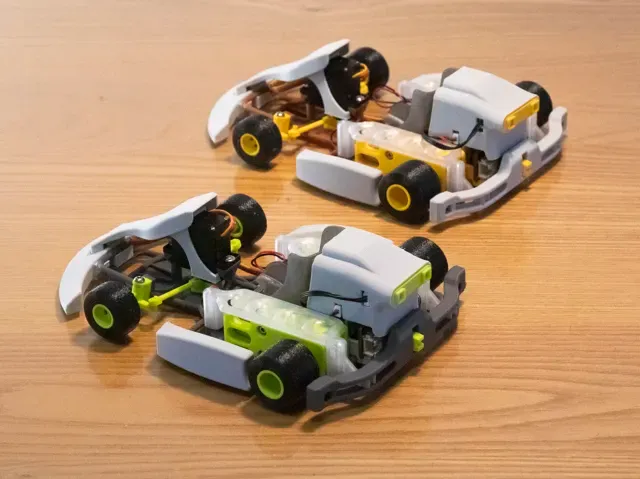
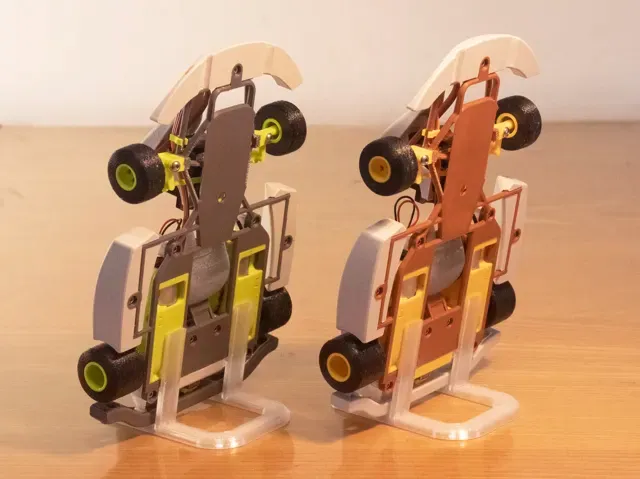
🏁 RK-12 🏁
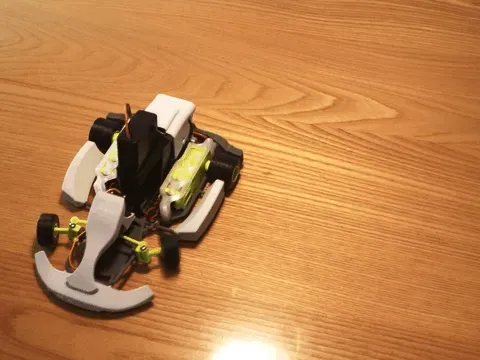
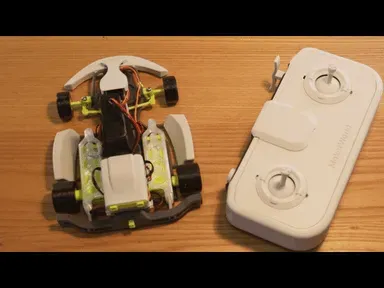
RK-12 — Realistic Kart (1:12 Scale)
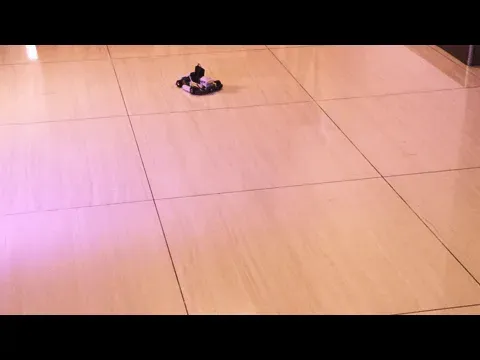
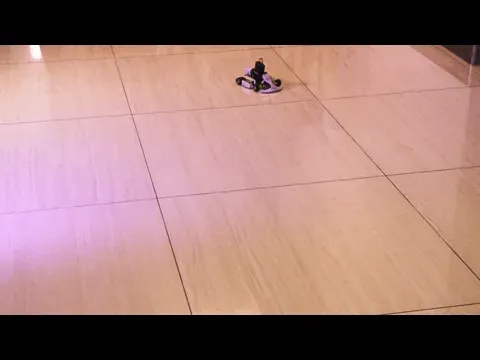
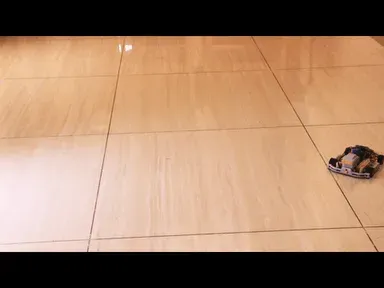
A 1:12 realistic go-kart that brings the track into your living room.
- Designed based on real competitive go-kart chassis and geometry - Responsive, direct steering with controllable light drifting - Pure kart driving fun, even in small spaces
Design Overview
- Realistic Go-Kart Driving Logic RK-12 is not a typical RC car. It is a 1:12 scale realistic model designed after real competitive go-karts.
From chassis proportions and steering structure to overall dynamic response, the goal is to recreate the direct, agile, and highly engaging driving feel that defines real go-kart racing.
- Precise and Direct Steering Feedback The model fully replicates a real go-kart steering linkage system , delivering highly responsive steering with almost no perceptible delay.
Every steering input is clearly translated into vehicle movement, making control intuitive and “connected” to the car.
- Lightweight Structure, Rapid Acceleration An optimized micro gearbox combines compact size and lightweight design with a 1:10.8 reduction ratio , enabling higher wheel speed and stronger acceleration.
Even with the battery and control electronics installed, the total vehicle weight is only 185 g , resulting in crisp, agile vehicle dynamics.
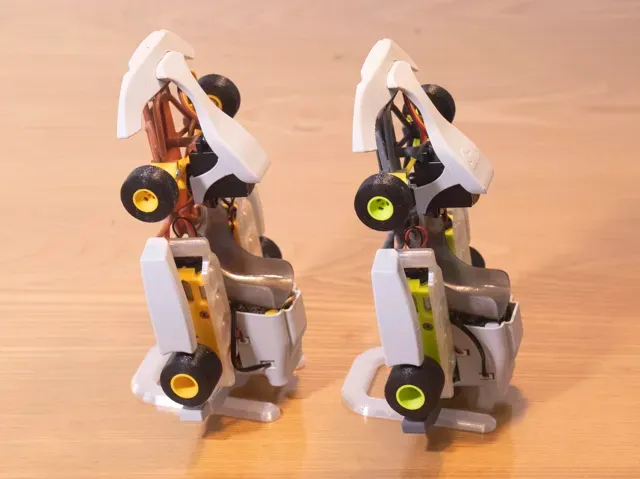
- Go-Kart Steering — Not a Differential Real go-karts do not rely on differentials. Instead, they use kingpin inclination to naturally lift the inner rear wheel during high-speed cornering, allowing the kart to turn on three wheels .
RK-12 preserves this core behavior and further optimizes it for the short travel of RC controller joysticks, maintaining stability and control while still allowing smooth, controllable light drift.
- No Track Required — Pure Driving Fun Whether hugging table edges or drifting smoothly around a sofa, RK-12 delivers agile steering and controllable light drift, bringing pure driving enjoyment even in limited indoor spaces.
Printing Materials
- Main parts: PLA Basic - Tires: TPU 90A - Seat: PETG Translucent (Some real go-karts use semi-transparent seats, which provide an excellent visual effect) - Not recommended: PLA_SILK and PLA_METAL, as they may cause strength issues
Printing Notes
The printing content is divided into two separate 3MF files:
- Main Parts – use a 0.4 mm nozzle. - Precision Parts – use a 0.2 mm nozzle. small parts(in the precision parts 3MF file)
- precision parts containing small parts should be printed with a 0.2 mm nozzle - For enclosed printers, ensure adequate cooling to prevent heat buildup around small parts - Applying glue to the build plate is recommended to improve adhesion of small parts
Tire Printing (in the main parts 3MF file)
- Tires should be printed with TPU 90A - You may pull sufficient filament length off the spool without cutting it ,This prevents periodic extrusion instability caused by spool drag - Ensure the loose filament does not tangle during printing - Applying glue to the build plate is recommended (In testing, TPU 90A adhered more strongly without glue , making removal harder)
Support Removal
- Begin removing supports from the corner areas of the chassis - Refer to the slicer preview and avoid damaging structural rods - Assembly
- Please refer to the included PDF assembly instructions
Adjusting JSON Parameters in Cyberbrick
The RK-12.json file provides a set of default vehicle parameters. If you encounter the following issues, adjustments can be made as described below.
1. Vehicle Does Not Track Straight — Adjust Midpoint Offset
Check mechanical alignment first:
- Ensure the servo horn is aligned with the servo 0° position - Make sure the four screws securing the gearbox to the chassis are fully seated, but not overtightened Software adjustment:
- Path: RK-12 → Angular Servo → Midpoint Offset (-10.0° ~ 10.0°) - Adjustment logic: - Decrease value → wheels turn right - Increase value → wheels turn left - Recommendation: - Adjust the integer value first, then fine-tune the decimal
2. Adjust Steering Sensitivity — Servo Angle Range
Default steering range:
- Min. Angle ~ Max. Angle = 55° ~ 125° Adjustment guidelines:
- Smaller range → more stable, easier control - Larger range → more aggressive steering, suitable for drifting - Maximum recommended range: 35° ~ 145° (Exceeding this may affect servo operation) Suggested combinations:
- (65 ~ 115) - (60 ~ 120) - (55 ~ 125) - (50 ~ 130) - (45 ~ 135) - (40 ~ 140) - (35 ~ 145) Parameter paths:
- RK-12 → Angular Servo → Min. Angle (0°~180°) - RK-12 → Angular Servo → Max. Angle (0°~180°)
3. Wheel Spin After Battery Upgrade — Reduce Acceleration
If:
- You upgrade to a 3S battery (11.1V) - And experience wheel spin on smooth floor surfaces You may reduce the acceleration value:
RK-12_Main parts 0.4mm
RK-12_Precision parts 0.2mm
Kart Track - Standard
Kart Track - Compact

Names are used only to indicate the source of a result. Polyzon is not affiliated with the listed sites.