
Free 
Magnetic encoder mount for hoverboard wheel motor (FFBeast, OpenFFBoard) - all in one solution (drill guide, assembly guide, encoder holder), even your grandmother can do it
Printables








If you appreciate my work and like it, you can buy me a coffee ;) but this is absolutely not expected.
Short introduction:
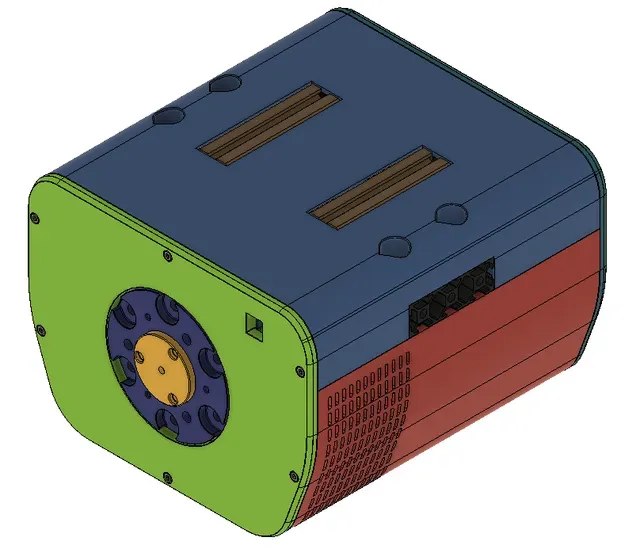
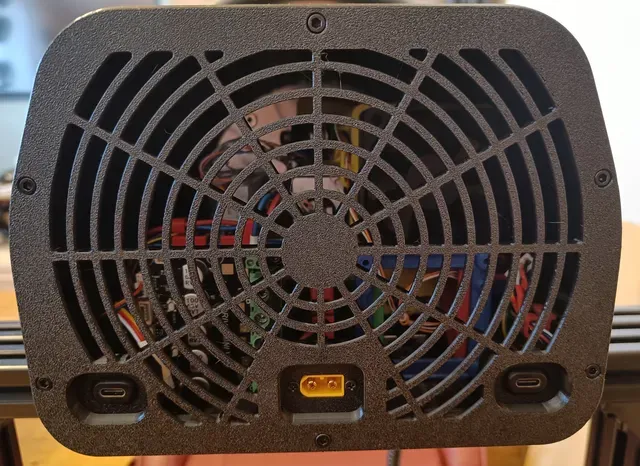
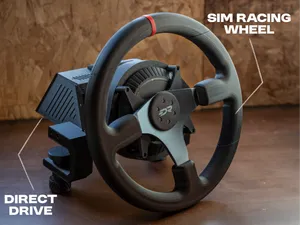
This design is created for 6,5" hoverboard motor with magnetic encoder. At the beginning wheelbase was build around FFBeast firmware which is using only oDrive Mini however during develompment fixation points for alternative OpenFFBoard firmware was implemented so if you want to you can use both solutions. Wheelbase has available slots for 2 USB-C sockets and XT60 socket on the back plate and RJ9 socket on the front plate. Power supply is not a part of wheelbase however please read carefully this chapter because wrong choice can fundamentally change FFB feeling.
Design explanation:
This design using 2060 and 2020 profiles and SK16 support bracket as a main structure assembly. Hoverboard motor is fixed by two SK16.
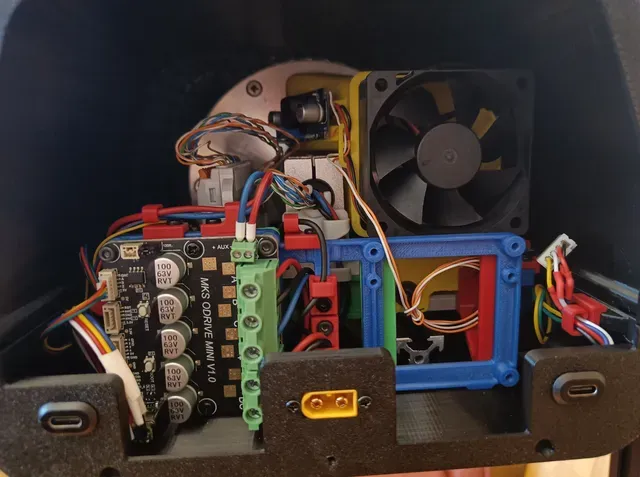
Electric parts (oDrive, OpenFFBoard, USB headers, XT60 header, RJ9 header) are fixed to the main 2060 profile by the 3D printed structure and to the bottom part. Braking resistor is fixed directly to the main 2060 profile. RJ9 socket is fixed between bottom part and front plate.
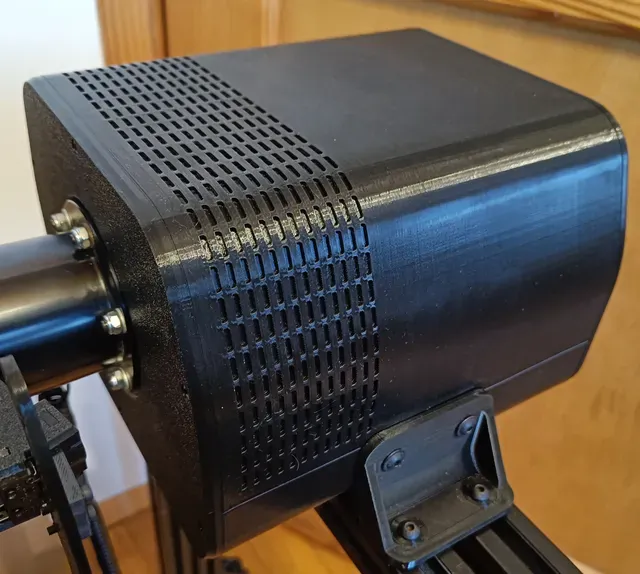
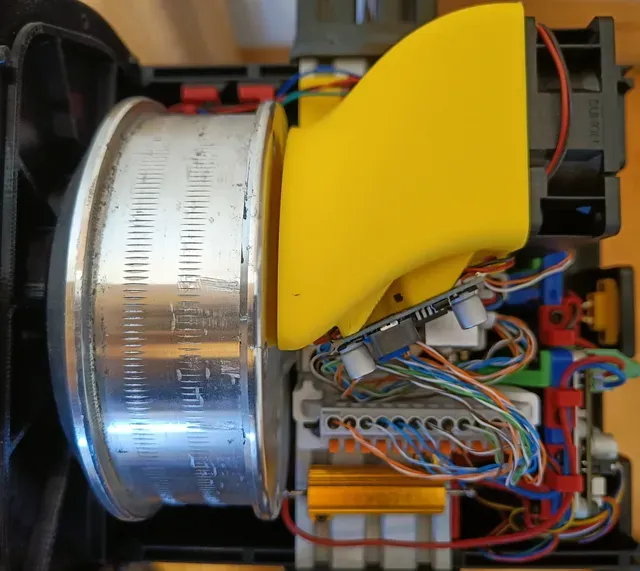
Design includes optional features like: cooling channel (designed for the 60x60x25 fan and LM2596 buck converter, inlet shape is covering more or less half of the back plate surface leaving second half for air outlet) and holder for 12-way wago (I was using this to connect additional lines for encoder debugging).
If you want to use cooling channel, back plate of the motor must have drilled venting holes.
Fixation methods:
You can mount wheel base to the simrig, table etc. directly with the screws and T-nuts to the bottom 2020 profile (distance between bottom profiles is 78,4 mm which fits Moza or Simagic screw patterns) or with the M5 screws by the two brackets screwed to the 2060 profile on the sides. Third method is using two extended brackets screwed to the 2060 profile on the sides with table clamps.
If you want to use side brackets you have to tap holes for the M5 screws in the 2060 profile.
Motor requirements:
This case is designed for the 6,5" hoverboard motor. Hoverboard motors can have different magnets – from 15mm to 30mm length, the longer magnets, the more powerful motor. It is not possible to distinguish between motors based on their external appearance but you can predict magnets length based on their weight. The weight of the motor with 30mm magnets (including tire) is 2.9kg or more. 30mm motor is highly recommended becauses even if you dont want to use max torque bigger motor with lower torque will heat less than smaller.
Motor must be modified to fix magnetic encoder on it. I would recommend MT6835 magnetic encoder (16384 PPR -> 65536 CPR) as a cheapest and robust solution (price difference with MT6701 is neglible but CPR downgrade is significant). Project with assembly video for required magnetic encoder holder is available here.
Power supply (THE MOST IMPORTANT PART!):
Power supply is one of the most important thing for the FFB experience. Knowing how hoverboard motor performs depending on voltage and current, we can select the right power supply. Wrong PSU selection cause significant negative FFB feeling and makes the wheel perform like garbage.
Let's start with motor rpm value. Commercially available wheel bases offer more or less 400rpm. The hoverboard motor (30mm) generates more or less 200rpm per each 12V (Kv around 17 rpm/V) therefore for 400rpm we need 24V. If you want more rpms, you can use 36V or higher but take in consideration max voltage of your odrive controller.
Second important factor is how max current is scaling with voltage. Motor phase resistance could be between 175 to 350 miliohms and as the default phase connection is star the resistance between two phases is from 350 to 700 miliohms. According to Ohm's law, in worst case maximum motor current I = 24V / 0,7 Ohm = 34A.
Third factor is max torque. The current determines torque generated by the motor (for most of the 30mm hoverboard motors Kt value around 0,5-0,55 Nm/A). Taking in consideration 24V we selected in previous paragraph from the current point of view 34A is the max you can physically push through the motor and it should gives 17-18,5 Nm but from the thermal point of view your motor will burn very fast (860W!!!). The realistic max current value for continous steering wheel usage is approximately 20A (this is guess) which gives you around 10-11Nm torque and does not damage your motor. Psu current we are searching for is not equal motor current, we have to calculate it from motor power: psu current = motor current ^2 * motor resistance / psu voltage = 20^2 * 0,7 / 24 = 12A. Keeping in mind all simplifications we took in calculation we can safely assume minimum 15A PSU. I would recommend 20A to have a margin on top of minimum.
Sumarizing: for 10-11Nm and 400rpm you need minimum 24V 20A (480W) PSU . Bigger voltage gives higher rpm, bigger power allows to get more torque however you can burn your motor quickly.
Dont get cheapest, random PSU from aliexpress because firstly the quality is unknown and secondly sounds like big vacuum cleaner.
Get weel-known brand like mean well or server PSU like hp common slot.
Assembly video:
BOM:
Main assembly:
- oDrive Mini - 1 pc (avoid ODESC - no pullup capacitors and problematic encoder lines capacitors to remove)
- OpenFFBoard - 1 pc if you want to use OpenFFBoard firmware
- Braking resistor 2 Ohm 50W - 1 pc (but should be in the oDrive bundle)
- RJ9 header - 1pc
- XT60E header - 1 pc
- USB-C header - 2 pcs
- USB-C connector - 1pc
- 6,5" hoverboard motor (30mm magnets) with magnetic encoder (MT6835) - 1 pc
- PSU 24V 20A (480W) - 1pc
- SK16 - 2pcs
- aluminum profile 2060 x 200 mm - 1 pc
- aluminum profile 2020 x 80 mm - 2pcs
- 2020 bracket - 4 pcs
- M5x8 ISO7380-1 - 8 pcs
- M5x18 ISO7380-1 - 4 pcs





Names are used only to indicate the source of a result. Polyzon is not affiliated with the listed sites.