無料 
Claw and Tank Robot
Thingiverse
This collection gathers 3D-printable parts for moving manipulators: articulated arms, wheeled platforms, walking robots and the drive modules that connect them. Most files are aimed at home 3D printing in common filaments, with servos or stepper motors added afterwards. It is useful if you are building a robot that has to reach, grip or travel rather than stay in one place. Polyzon does not confirm whether models are free, their price, license, official status, affiliation, safety or fitness. Check the current terms at the source.
このコレクションの本文は英語で書かれています。検索自体はどの言語でも使えます。
 Polyzonのコレクション · モデル46件 4サイトから収集
このコレクションは、Polyzonが対応サイトの検索結果をもとに作成しています。重複やプレビューのないモデルは除外し、関連性の低いものは後ろに回し、それ以外は検索結果の順に並べています。モデルの権利は各作者にあります。利用条件は各モデルのページでご確認ください。
選定基準:Polyzon編集部 · 本文の更新日:2026年10月14日


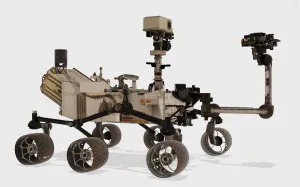

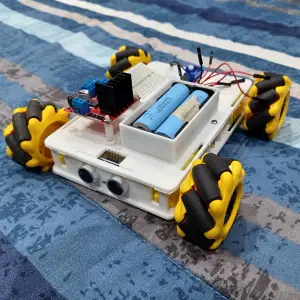

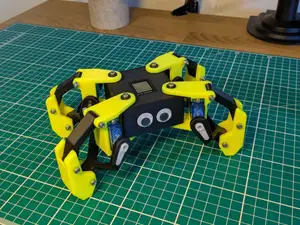
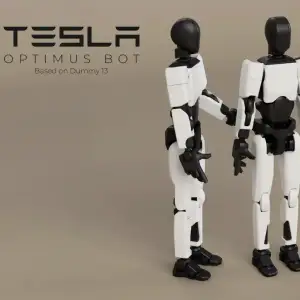


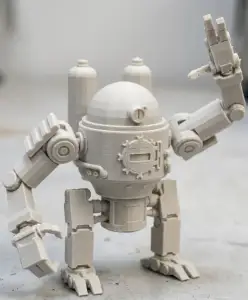

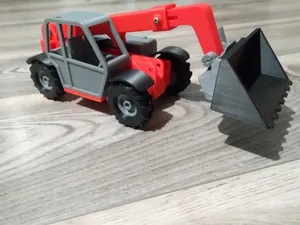
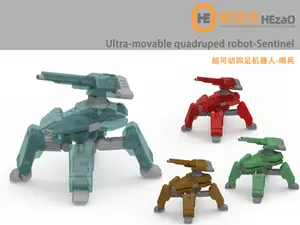

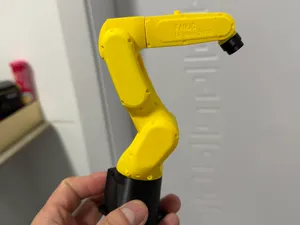
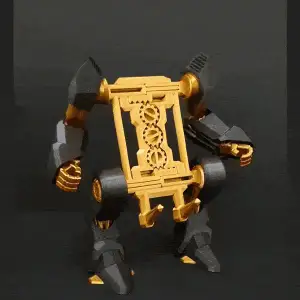

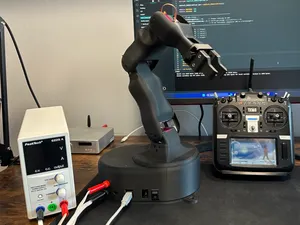


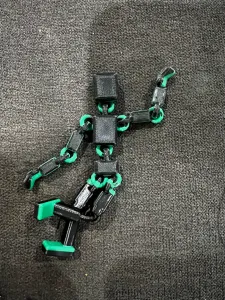



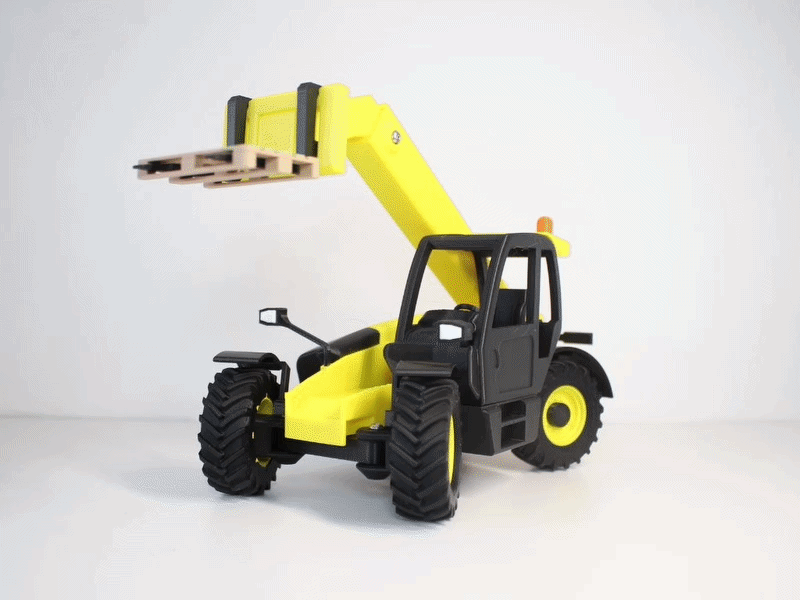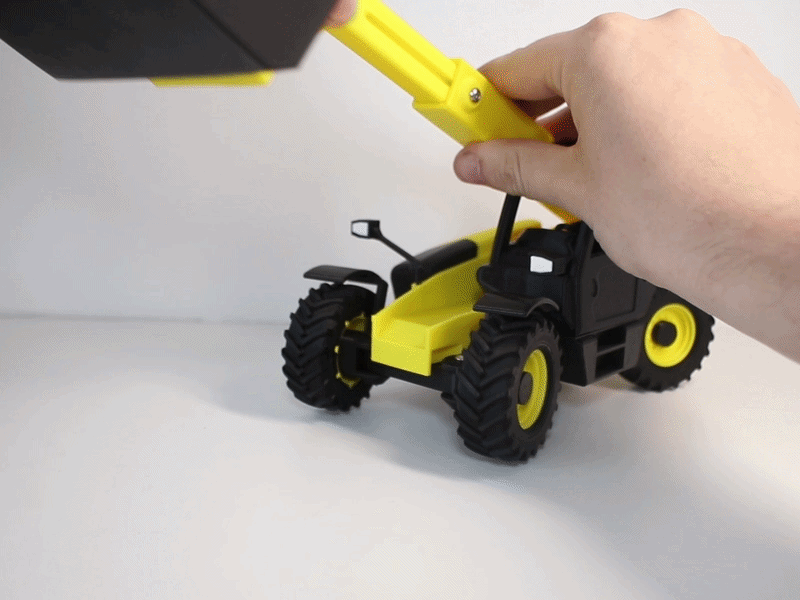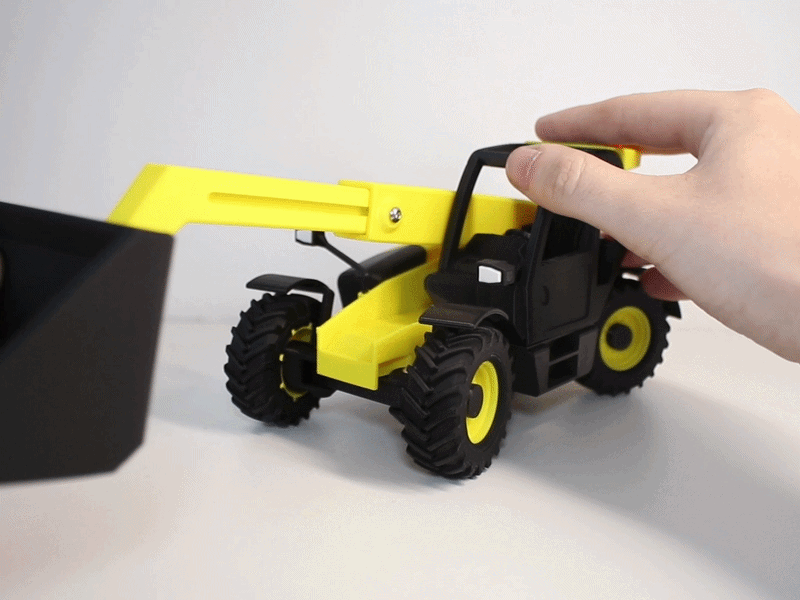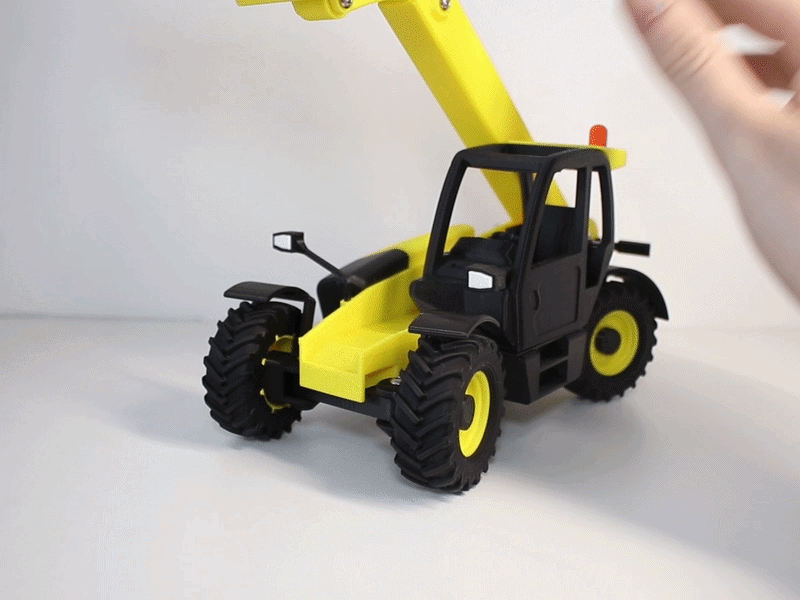

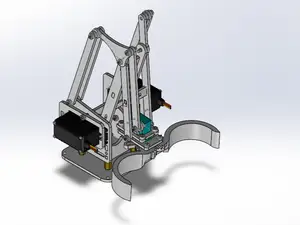
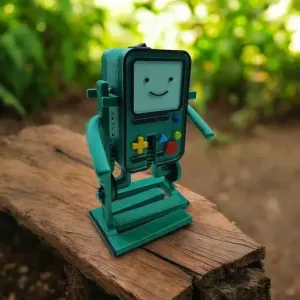
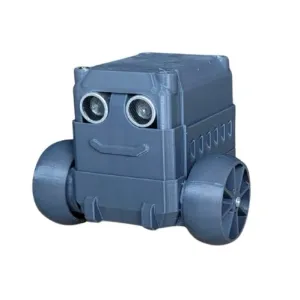
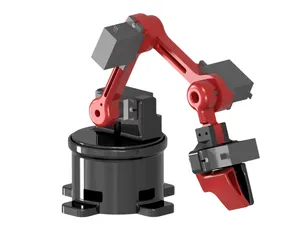

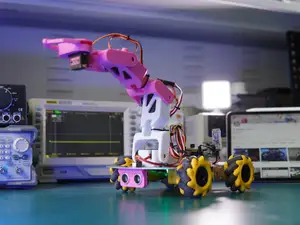


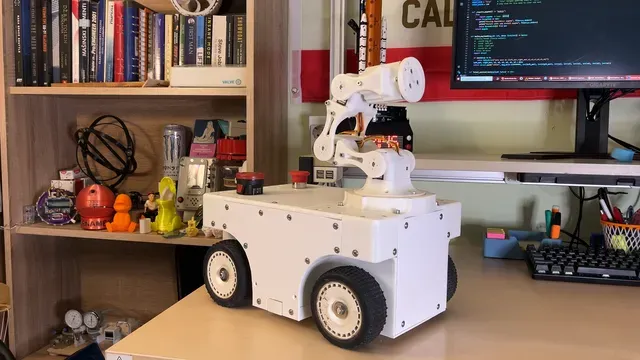
The models split roughly into two groups. One covers arms and end effectors — rotating joints, links and claws that give a mechanism its reach. The other covers the base: wheeled chassis, omniwheel mounts, legged frames and gearbox housings that move the whole assembly. Some designs combine both, so a printed arm sits on a printed rover.
When choosing a model, read the author's page before printing. Check the stated scale and link lengths, how many parts the assembly has and how they fasten, whether supports are needed on overhangs, and which motor or servo sizes the joints are shaped for. Look at photos of finished builds to judge clearances and wall thickness, and note the material and layer settings the author lists.
To widen the search, try related terms such as robotic arm, manipulator joint, gripper, rover chassis, differential drive, omniwheel, servo bracket or planetary gearbox. Searching by function — reach, lift, grip, steer — often finds parts that a single keyword misses, and browsing a designer's other models can reveal matching brackets and mounts.
Printing a moving mechanism puts different demands on a 3D printer than a static model. Tolerances at pivots, holes for bearings and shafts, and the stiffness of long links all matter, so test-fit a single joint before committing to a full set of parts. If a joint binds, adjusting the layer height or printing the part in a different orientation is usually more effective than scaling the file.
暮らし・日用品からCNCまで、すべてのテーマをそろえたカタログ。対応サイトを横断して検索できます。