
Бесплатно 
15:1 Compact Nema17 Cycloidal Drive
MakerWorld
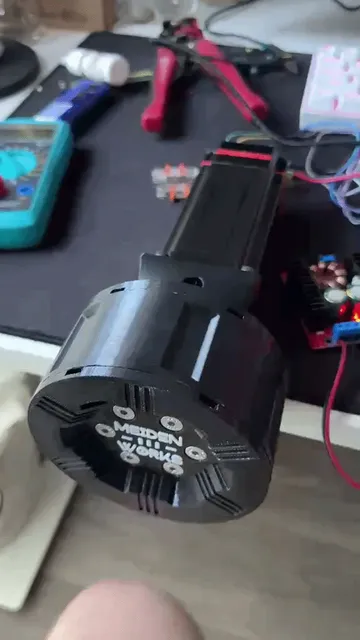
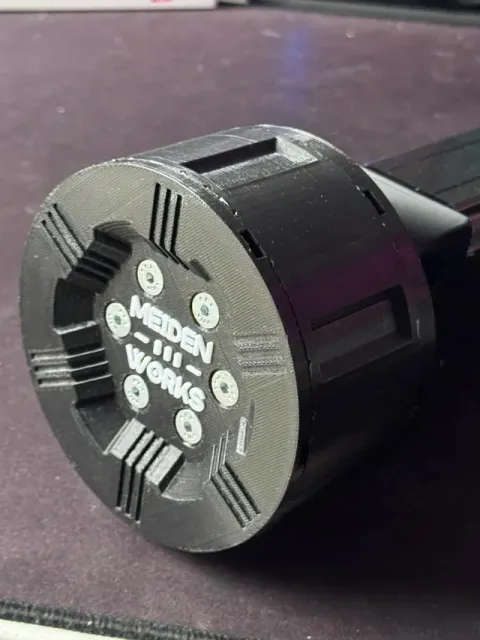
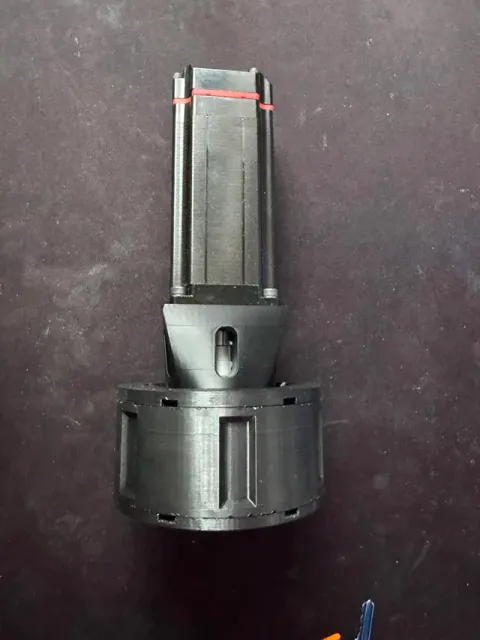
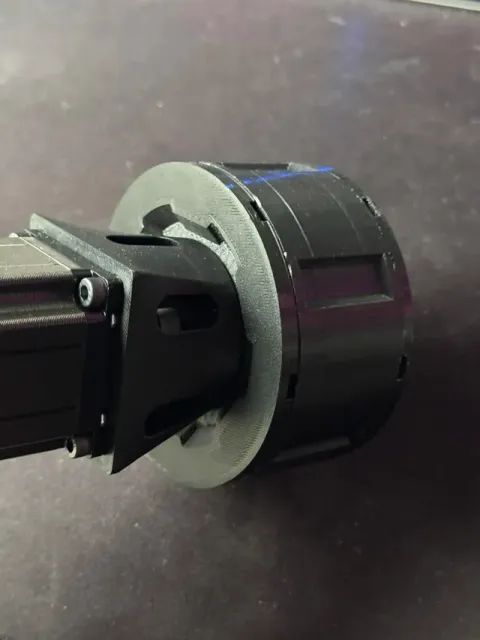
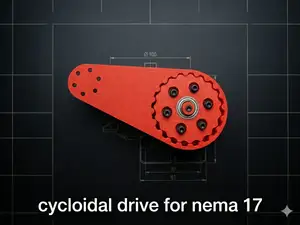
Boost Me Thank you for printing! 🦾 This NEMA 23 Cycloidal Drive is the first building block of my full-scale robotic arm project. If this high-torque actuator meets your expectations, please consider leaving a Boost! Your support directly funds the R&D and filament for the next robotic joints I’m currently developing. Let's push the limits of 3D-printed robotics together! 🚀 🤖 TRANSPARENCY NOTICE: The engineering, CAD design, and 3D files are 100% human-made. Generative AI was used EXCLUSIVELY to create the promotional render image and to assist in formatting this text description.
Overview
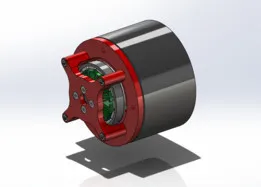
Bring serious torque to your DIY robotics without sacrificing space. Meiden Works Actuator is an ultra-compact, high-performance cycloidal drive engineered specifically for NEMA 23 stepper motors.
Whether you are building a custom robotic arm, modifying a CNC machine, or working on automation projects, this "pancake-style" gearbox keeps your center of gravity tight while delivering massive rotational power.
Key Specifications
- Gear Ratio: 8:1 - Output Torque: Up to ~20Nm (theoretical, heavily dependent on your filament choice and print settings) - Motor Compatibility: Standard NEMA 23 - Profile: Ultra-flat design (Approx. 56mm total thickness) - Design: Fully functional, robust, and optimized for 3D printing. Hardware Required (Non-Printed Parts)
To assemble this gearbox, you will need standard hardware. No special custom metal parts are required:
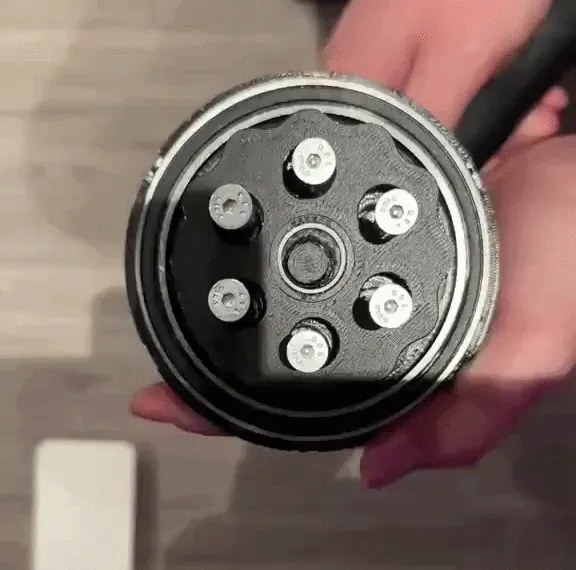
- Stepper Motor: 1x NEMA 23 - Bearings: 4x 6802 2RS 15x24x5mm | 2x 6816-2RS 80x100x10 mm | 2x 6800RS 10x19x5mm - Screws (Motor mounting): 4x Socket Head M5x12mm - Screws (Assembly): 6x Countersunk M5x60mm - Pins/Rollers: 6x M5x30mm Unthreaded Aluminum Spacers (Note: Applying a small amount of lithium or silicone grease to the cycloidal disc and pins will drastically improve efficiency and lifespan).
Print Settings & Recommendations
This is a high-torque mechanical part. It needs to be strong!
- Material: PETG, ABS, ASA, or PC/Nylon recommended. PLA+ can work for testing, but standard PLA may deform under heavy load or motor heat. - Walls/Perimeters: Minimum 4-6 walls for rigidity. - Infill: 20% - 60% (Gyroid or Cubic pattern for multi-directional strength). ⚠️ DISCLAIMER REGARDING AI USE: I want to be completely transparent with the community: The 3D model itself, the mechanics, the tolerances, and the physical testing are entirely my own manual work. Generative AI was ONLY used for two things: generating the cover render/image and helping to write this text description. No AI was involved in the engineering or CAD process.
PETG Optimized: 0.2mm, 4 Walls, 20% Infill Pre-configured profile optimized for PETG:
• 0.2mm layer height
• 4 wall loops (crucial for gear rigidity)
• 20% Gyroid infill (for multi-directional strength)
• Supports are already placed and configured in the file
• If you find the fit too tight, adjust the 'XY Size Compensation' (or 'XY Hole Compensation') by +-0.05mm in your slicer
⚠️ IMPORTANT: This profile was specifically tested and optimized for PETG. Standard PLA is not recommended for high-torque applications.



Названия используются только для указания источника результата. Polyzon не аффилирован с перечисленными площадками.