
€ 3.99 
Educational Gear Board STEM Kit for Kids – 3D Printable Mechanical Learning Toy
Cults3D






Spoiler: I have not created 507 models; the name refers to the book “507 Mechanical Movements” by Henry T. Brown from 1868. The book is also available as an online version with animations. You should definitely take a look at it.
Such books are extremely helpful for finding inspiration in design problems. But even better than graphics are haptic movement models, on which pupils and students can try out the mechanisms in practice.
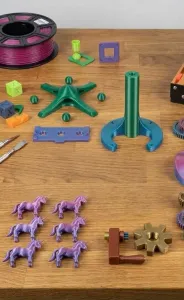
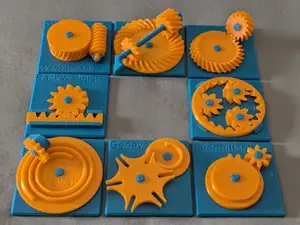
These 3D models capture the essence of the original movements, allowing for interactive exploration and understanding of the mechanical principles behind them.
Overview:
The numbers of the models correspond to the numbers in the book. This number is also always embossed into the models.
The yellow part is the one that should be moved. In some cases, other components can also be moved.
No. 1 & 2:
Description:
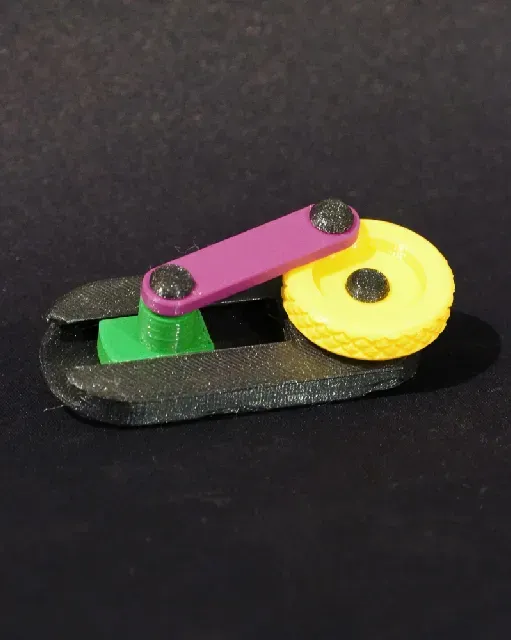
A classic belt drive is utilized in many applications. Belt drives come in various forms, including flat belts, round belts, and the most commonly used type, the V-belt. These belts exhibit some slip, which means that when an engine starts up strongly, the belt may slip slightly on the pulley. This characteristic allows for a smoother startup compared to other solutions.
3D-Modell:
In this model, I have used a rubber band as the belt. The belt can also be tensioned crosswise, enabling the driven pulley to rotate in the opposite direction.
Model files plus two rivets.
No. 24:
Description:
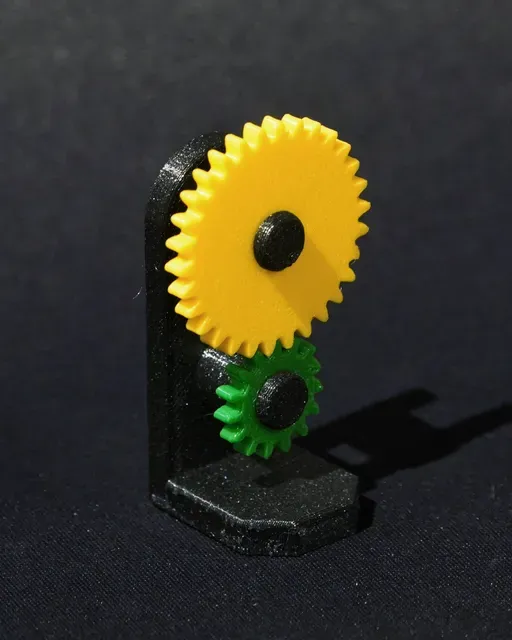
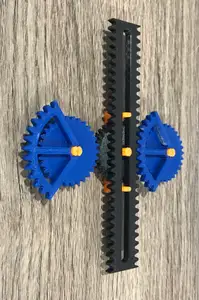
Gear wheels offer high positioning accuracy. When designing, it should be noted that only the same tooth sizes can be combined with each other. These sizes are called module. The pitch diameter is crucial for determining the spacing between the gears. Different gear sizes create a transmission ratio, which alters the speed between the input and output. The shape of the teeth is also particularly interesting. This is called an involute. This shape causes the teeth to roll over each other.
3D-Modell:
The gear wheels on the model have 30 and 15 teeth. This means that the small gear wheel rotates twice as fast as the large one.
Model files plus two rivets.
No. 25:
Description:
With bevel gears, the rotational movement is deflected by an angle, usually 90°. In addition, gear wheels of different sizes can be used, creating a transmission ratio as with normal gear wheels. The angles between the teeth of the gears are important here.
3D-Modell:
The model has gears with 45 and 15 teeth, resulting in a gear ratio of 1:3.
Model files plus two rivets.
No. 31:
Description:
A worm gearbox typically has a very high transmission ratio. The worm must rotate around its axis as many times as there are teeth on the driven wheel. There are also worm gears with several threads. This changes the transmission ratio accordingly. The driven wheel is self-locking in such gear units. Also note that the teeth of the gearwheel are at an angle. This angle corresponds to the thread pitch.
3D-Modell:
The gear wheel has 20 teeth, which means you have to turn the worm 20 times until the gear wheel has rotated once around its own axis.
It is not easy to fasten the rivet in this model. The best way to do this is to press them in upside down with a pen.
The worm wheel consists of three individual parts. This is necessary so that the thread flanks are printed properly. The individual parts must be glued together with superglue.
Model files plus one rivet.
No. 34:
Description:
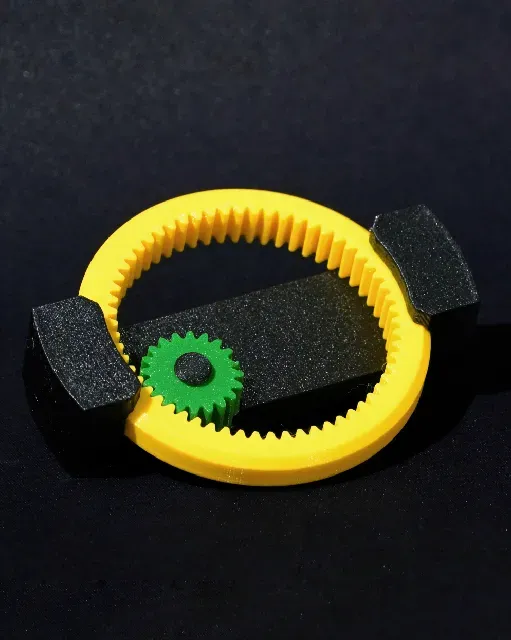
A ring gear is essentially a gear wheel turned inwards. This enables a space-saving arrangement of the gears. However, the outer gear wheel must be considerably larger than the inner one. This principle is used in a planetary gear (No. 55).
3D-Modell:
The outer gear wheel has 60 teeth and the inner one has 20, which means that the transmission has a ratio of 3:1.
During assembly, the outer gear must be fitted together with the pin. The smaller gear can then be inserted.
Model files plus one rivet.
No. 50:




Названия используются только для указания источника результата. Polyzon не аффилирован с перечисленными площадками.