
Бесплатно 
3WD RPi-flex PCB robot
Printables


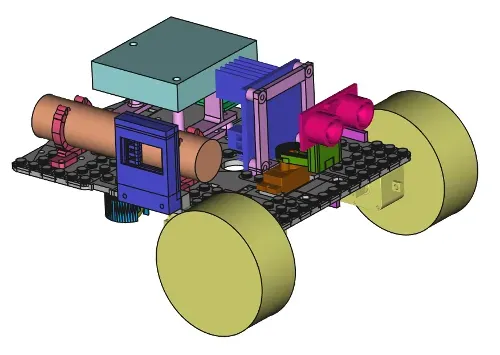
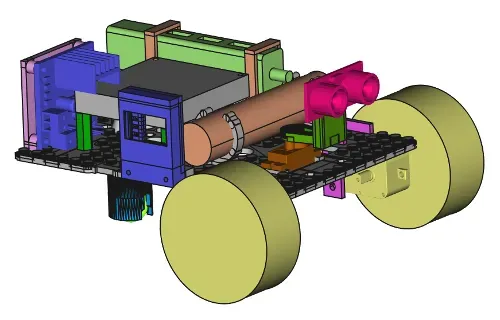
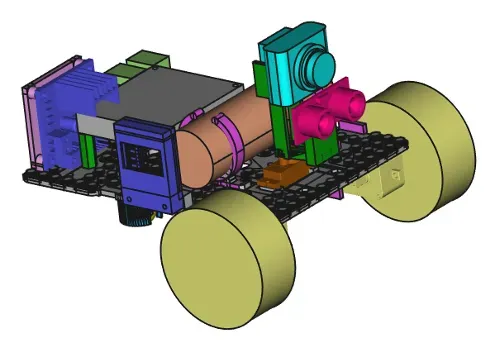
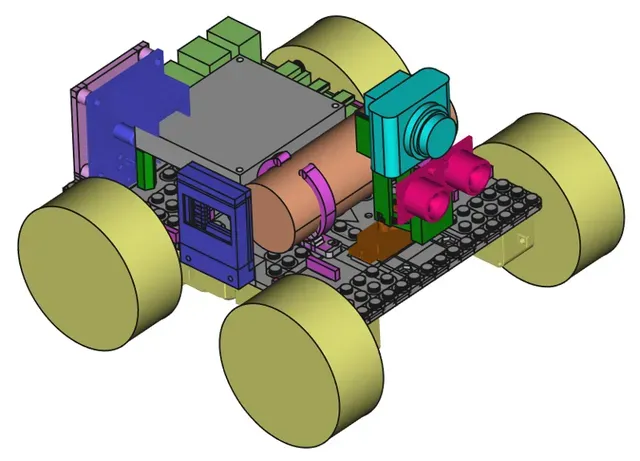
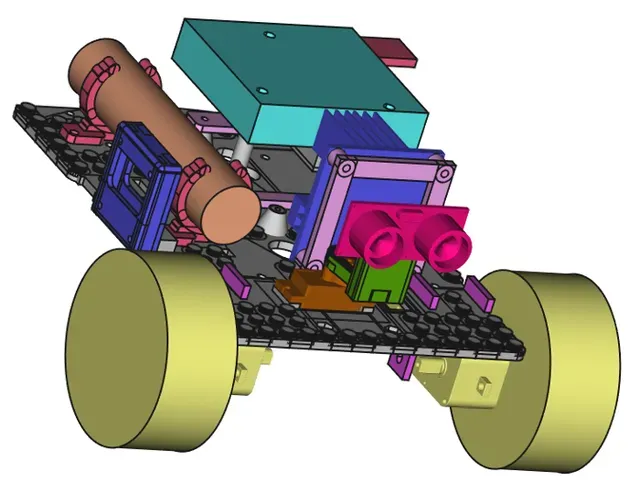


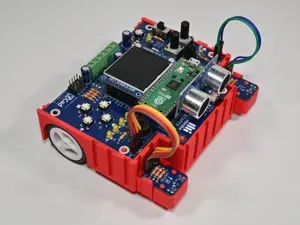
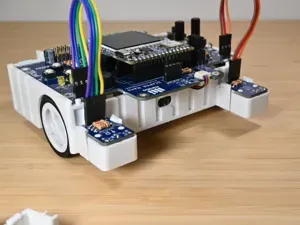
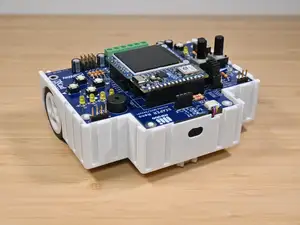
A set of printed components to build 2WD or 4WD robots that can be controlled and managed by any of the Raspberry Pi single board computers (SBCs), a Raspberry Pi Pico microcontroller or an ESP32 microcontroller - where the use of mecanum wheels with custom adaptors for 4WD designs managed by a Raspberry Pi is also now an option.
Detailed descriptions of all aspects of this evolving project are at this link with additional information on the mecanum build option at this link .
The main, single plate 3D printed chassis is designed to allow a standard set of drive, sensor and other components to be assembled in a number of different arrangements to allow different build configurations. It has also been designed to allow individual customisation with Lego blocks and/or card cut-outs that insert into custom 3D printed Lego-compatible blocks (the files for the LEGO-compatible blocks for card cut-outs are available here ).
All the components use 1.75mm PLA and a layer height of 0.15mm with print details for each component produced on an i3 Mk3 shown in the table below.
Updates :
- update May'25 to include a spacer to create space between the 4 slide switches and the PCB top surface to minimise the possibility of solder wicking up and creating short circuits to the switch metal casing - update May'25 to the main chassis plate to support 4WD mecanum builds with some further design tweaks and the addition of embedded version text - update May'25 to update the L298N cradle and to provide a pair of cradles in the .stl file - main chassis plate updated 17th Sept'21 to correct servo and ON/OFF rocker switch cut-outs
component file name/description needs support (Y/N) brim (mm) filament length (m) print time (i3 Mk3)
mega-flex_chassis_plate25-mechanum_repaired.stl: main chassis plate with Lego-compatible studs on the top surface (updated May'25) N 10 15.90 5h 19m
mecanum_wheel_adaptor05_roty180.stl: custom adaptor for connecting a mecanum wheel to the geared drive motor axle N 3 0.75 36m
4x_motor_fixing_tab02.stl: tabs that insert into the chassis plate to secure the drive motors N 3 1.36 31m
slide_switchx4_spacer01.stl : slide switch spacer N 0 0.11 4m
2x_L298N_vcradleExHi_s-lugs02_roty90.stl : vertical fixing mount for a L298N motor controller N 0 2.41 1h 3m
H C-SR04_transverse_fixed_plate01.stl : fixed ultrasonic sensor mount N 0 0.6 20m
HC-SR04_servo_holder02.stl : servo mounted ultrasonic sensor N 0 0.81 25m
HC-SR04_Pi-cam__transverse_fixed_plate05.stl : fixed mount for ultrasonic sensor and Raspberry Pi camera N 0 1.46 1h 0m
HC-SR04+camera_servo_arm09.stl : servo mounted ultrasonic sensor and USB camera mount N 5 2.35 1h 35m
OLED1_flat08-front+back.stl : 128x64 OLED 2pc mount assembly for the 27.3 mm wide and 27.8mm high OLED N 0 2.64 1h 15m
OLED2_flat05-front+back.stl : 128x64 OLED 2pc mount assembly for the 24.7mm wide and 27.0mm high OLED N 0 2.77 1h 16m
32mm_top_open__left-right_bat_holder02.stl : 32mm 5000mAh 5V/2A battery bank mounting clips Y 0 2.21 52m
21mm_top_open__left-right_bat_holder01.stl : 21mm 3350mAh 5V/1A battery bank mounting clips N 0 1.25 33m
stretched_40mm_caster_loose03.stl : front or rear castor that holds a marble ball N 5 2.55 1h 34m
mega-flex_RPi_maker_kit_2x_spacer02.stl: two hexagonal spacers that secure the overhanging portion of the RPi Maker Kit PCB to the chassis plate. N 5 0.63 27m
PiZero_mount01.stl : PiZero 'mount' that screws to the chassis plate and this then aligns with the outer pair of the PiZero mounting holes. N 0 0.55 19m
mega-flex_USB_adaptor_holders_left01+right01.stl : mounts to secure a 3 port USB + ethernet adaptor to the chassis plate which overcomes the lack of multiple USB ports on a PiZero N 0 1.65 42m
ESP32_side_leg01.stl : ‘legs’ that attach one side of the ESP32 Maker Kit PCB to a separate mount (see below) that attaches to the chassis plate N 0 0.69 26m
ESP32_side_leg_mount01.stl : chassis plate mount for the side 'legs' refrenced above N 0 0.37 16m
mega-flex_ESP32_maker_kit_centre_leg01.stl : ' leg' that attaches the other side of the Pico Maker Kit PCB to the chassis plate N 0 0.61 18m
Pico_mount01.stl : leg mount for attaching one side of the Pico Maker Kit PCB to the chassis plate N 0 0.89 39m
Pico_side_leg01.stl : leg mount for attaching the other side of the Pico Maker Kit PCB to the chassis plate N 0 0.61 18m
mega-flex_PCB_mounts01-left+right.stl : pair of mounts for the custom PCB that can connect any of the system controller options N 0 1.82 59m





Названия используются только для указания источника результата. Polyzon не аффилирован с перечисленными площадками.