Grátis 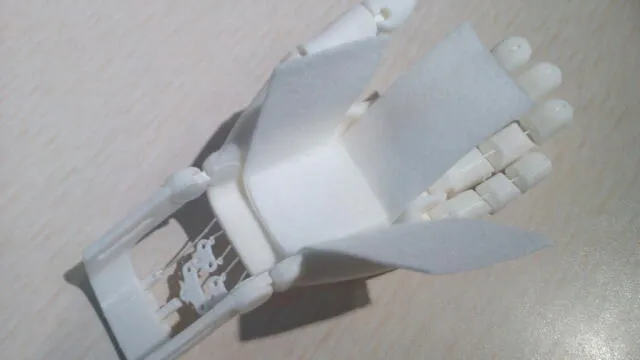
Робо рука
3DToday
This collection gathers 3D models of robot hands, fingers and arms prepared for 3D printing. It covers poseable articulated hands, print-in-place mechanisms, scaled-down versions and the stands that hold them. Use it to compare approaches before opening an author's page. Polyzon does not confirm whether models are free, their price, license, official status, affiliation, safety or fitness. Check the current terms at the source.
O texto desta coleção está em inglês; a busca funciona em qualquer idioma.
 Uma coleção do Polyzon · 48 modelos de 11 sites
O Polyzon monta esta coleção a partir dos resultados de busca dos sites conectados. Repetições e modelos sem prévia são removidos, correspondências fracas vão para o final e o restante segue a ordem da busca. Os modelos pertencem aos seus autores — confira os termos na página de cada modelo.
Regras de seleção: equipe editorial do Polyzon · Texto atualizado em 11/10/2026




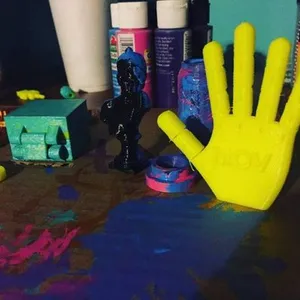

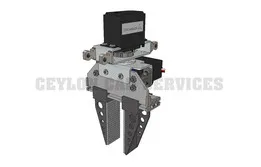
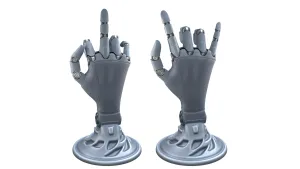

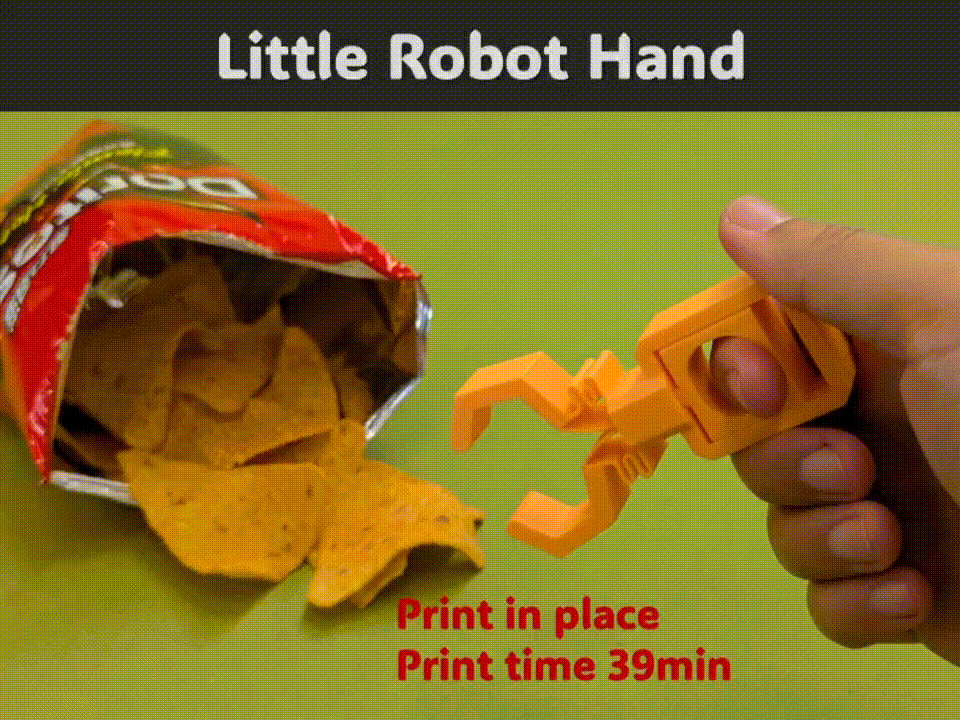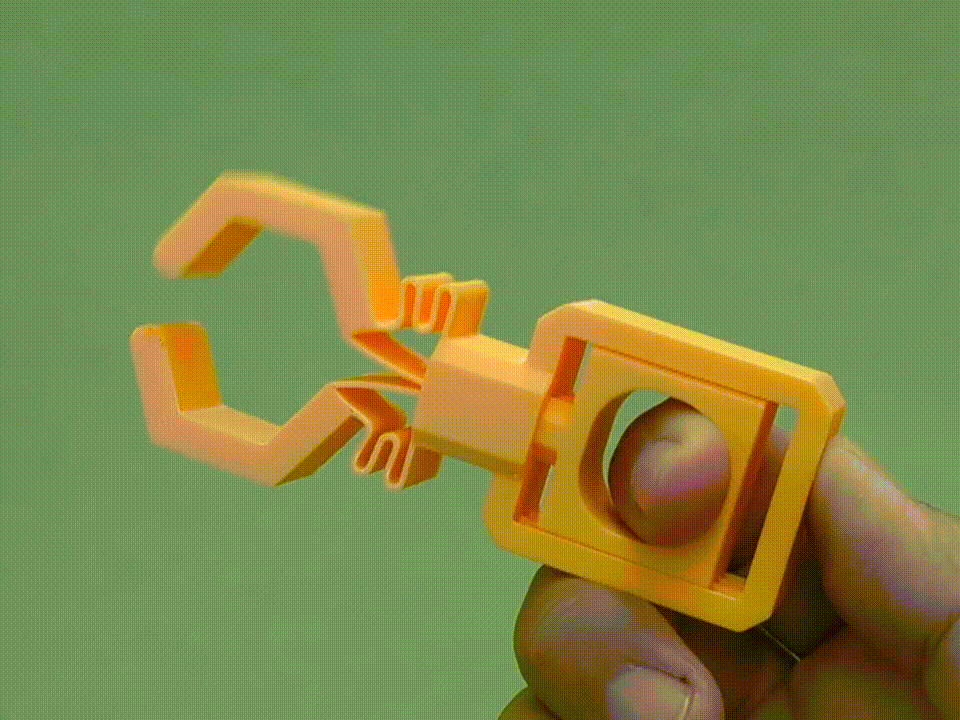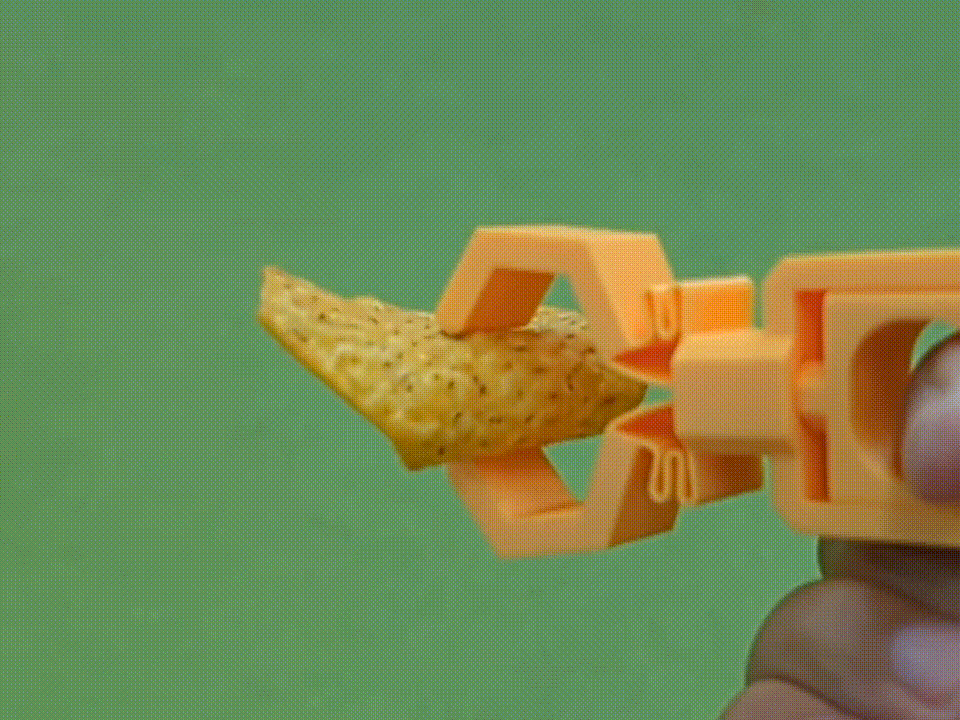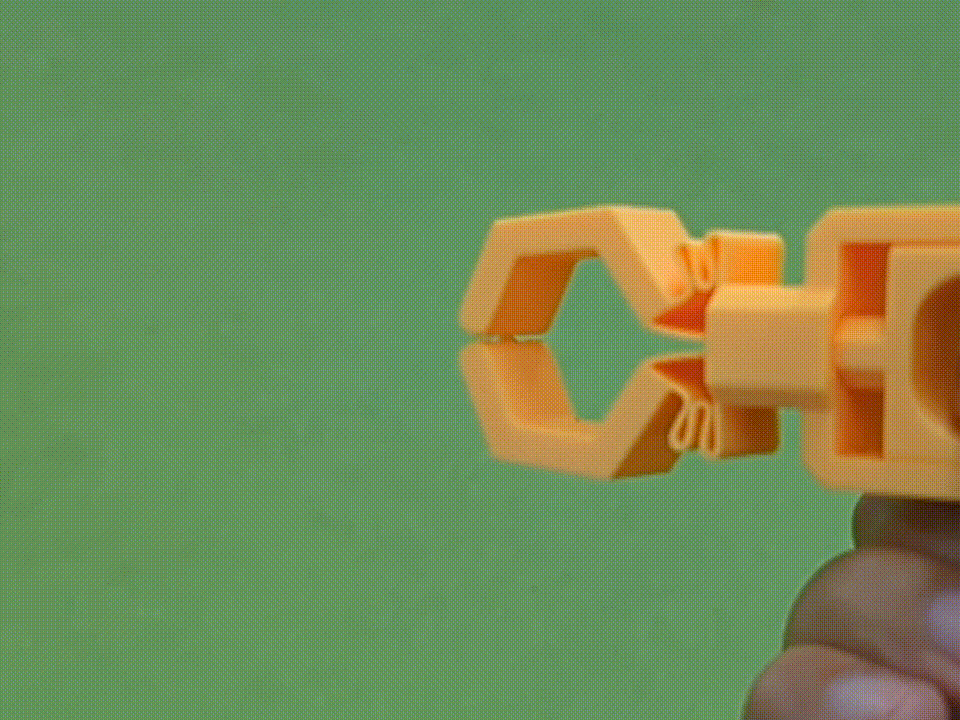

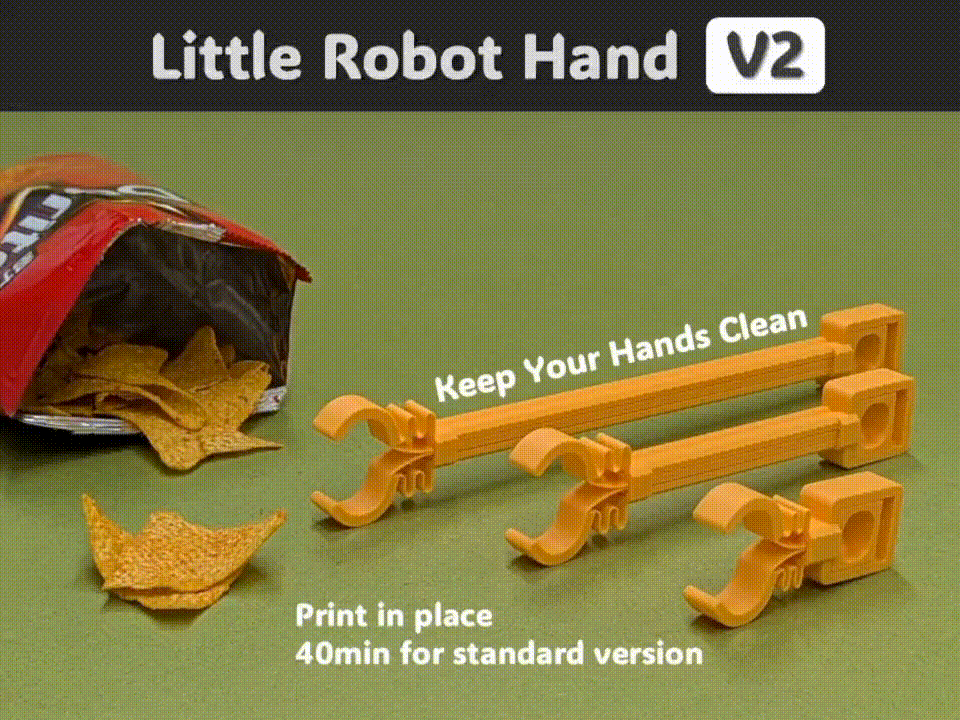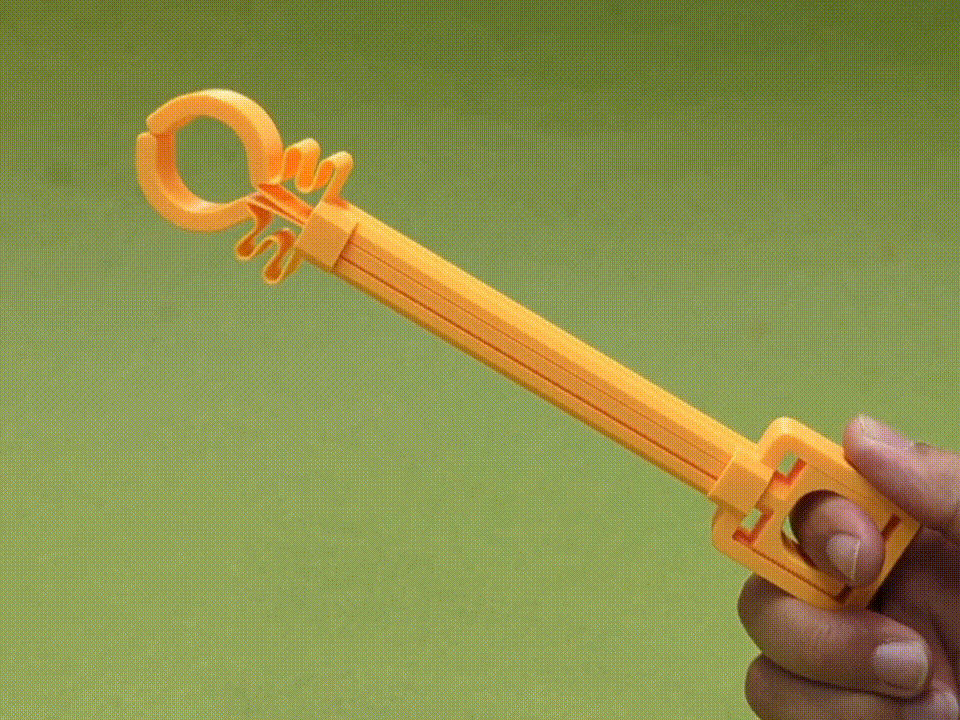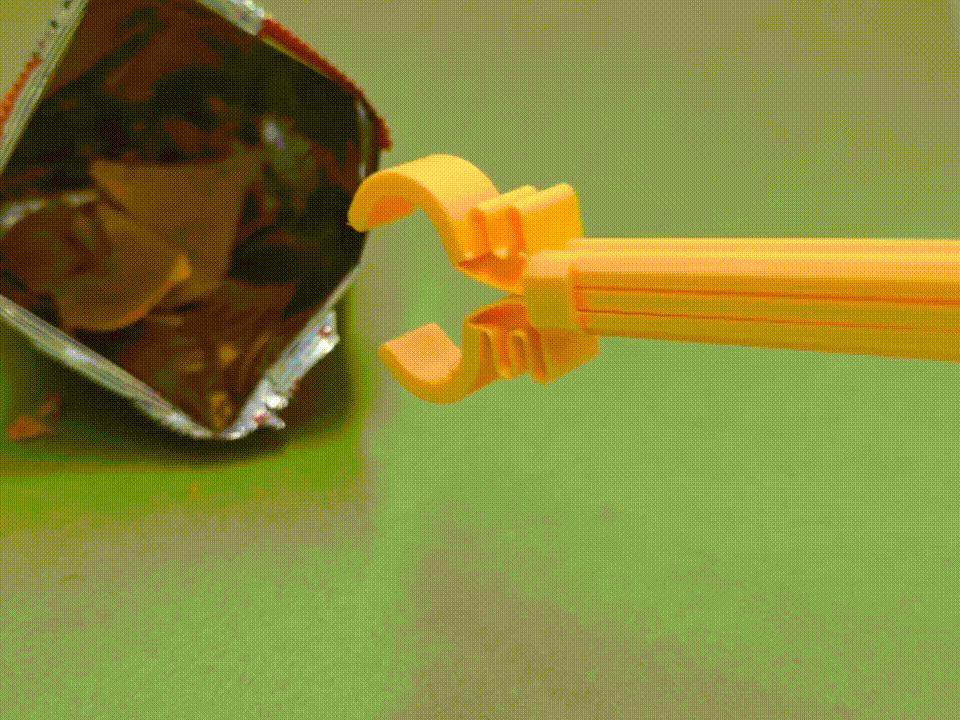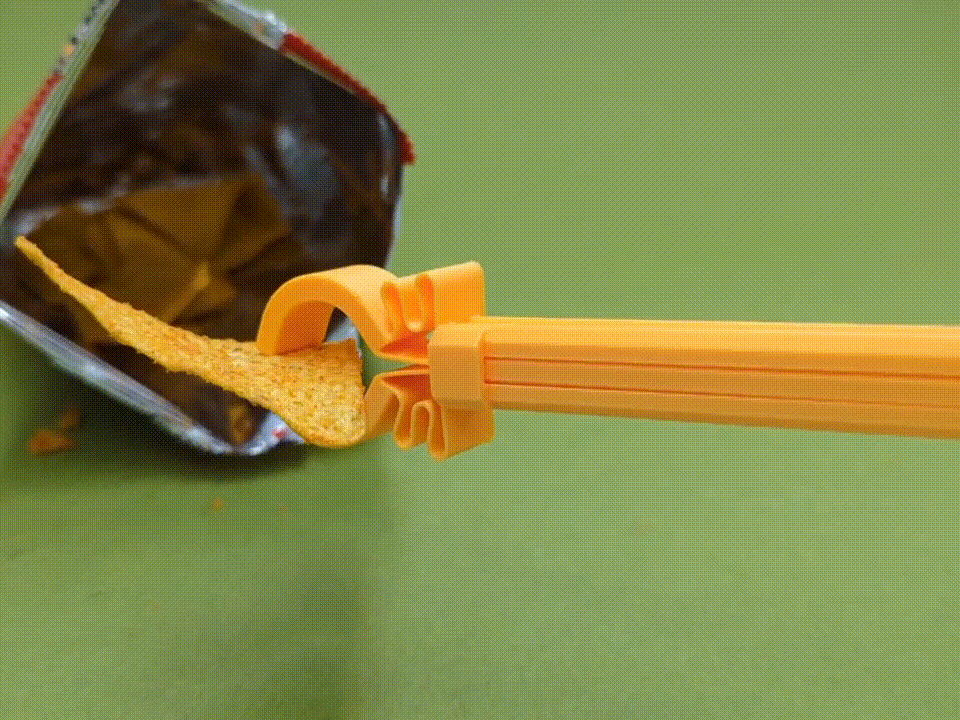


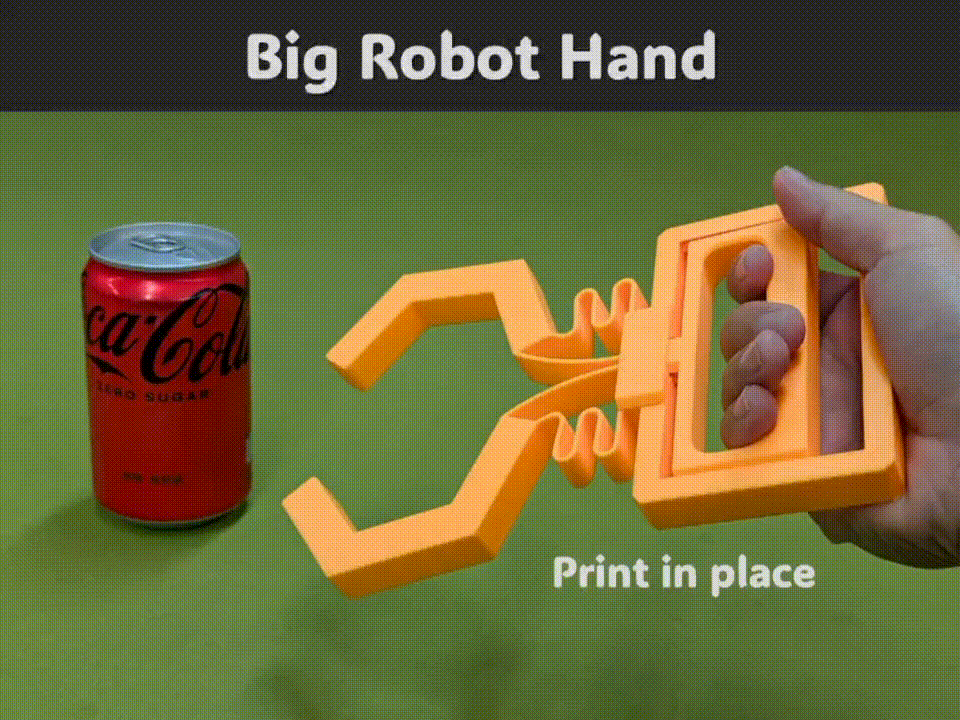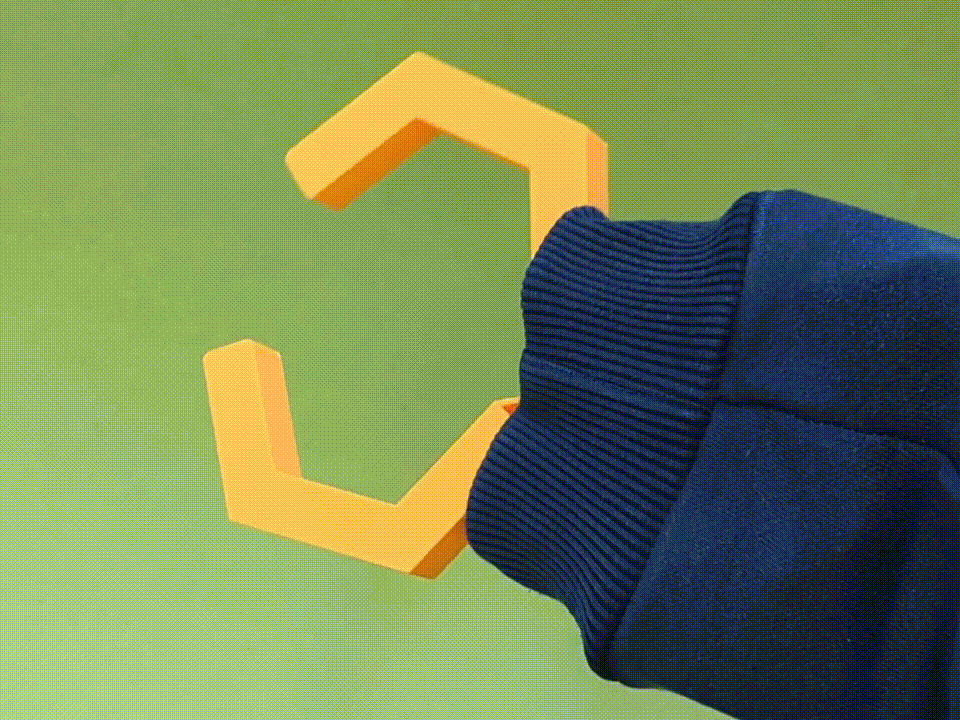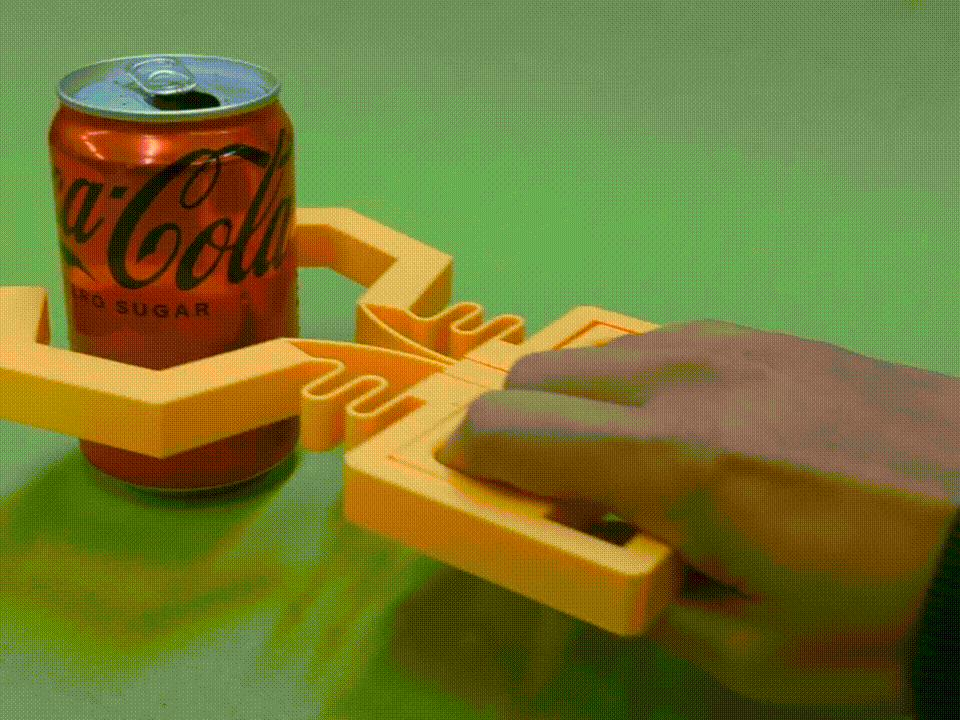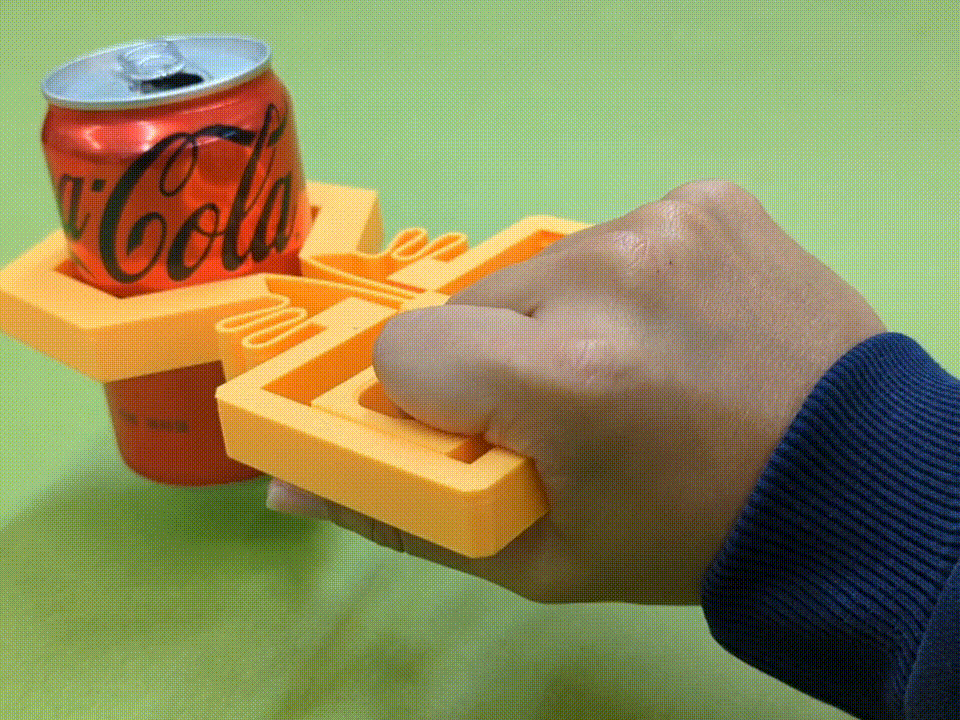
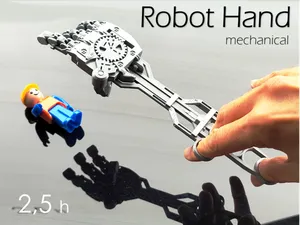

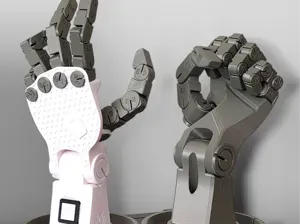



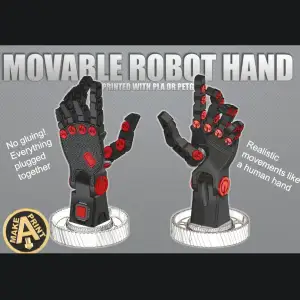

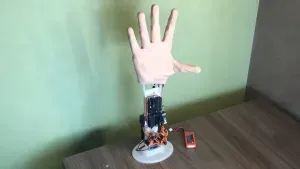

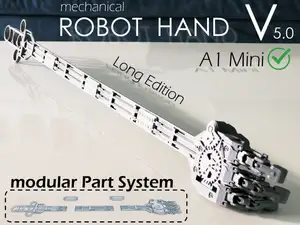

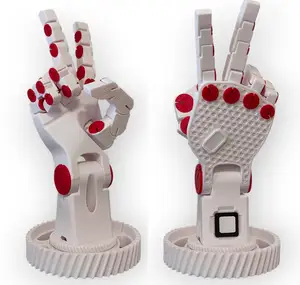
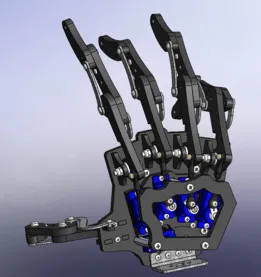

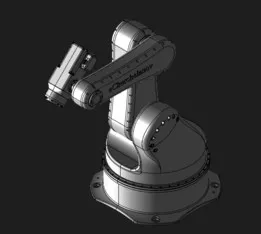
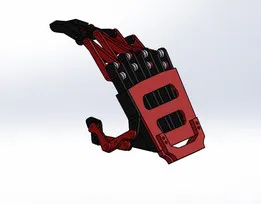
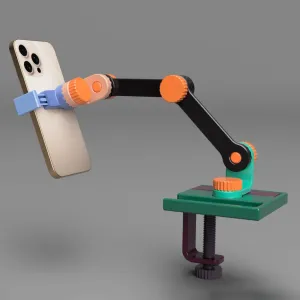
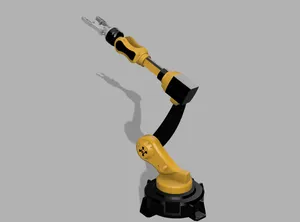
The models fall into a few groups. Poseable hands use separate finger segments joined by pins or printed axles, while print-in-place designs come off the printer with the joints already formed and often include a screw or tensioner to set stiffness. Full arms add several degrees of freedom at the wrist, elbow and shoulder, and scaled variants shrink the same geometry for smaller builds. Stands and controller mounts are simpler parts that keep a finished hand upright or attach it to a gamepad.
When choosing, check the hand side and scale first, since left and right versions are usually separate files. Look at the part count and assembly notes, whether the author expects supports, and the material and layer settings listed on the page. Photos of real prints show how the joints fit and where clearances matter; pin and socket tolerances are the usual reason a hand ends up too stiff or too loose.
To widen or narrow the search, try synonyms such as robotic hand, bionic hand, mechanical hand, gripper or end effector, and combine them with terms like articulated, poseable or print in place. Related topics include robot arms, prosthetic prototypes, finger mechanisms and display stands. Adding a material name or a scale keyword filters the results further.


O catálogo completo de temas — de casa e utilidades a CNC, com busca em todos os sites conectados.