免费 
Octahedral Hexapod Mechanism (Parallel Robot)
GrabCAD
This collection gathers hexapod 3D models for 3D printing, including walking robots, parallel platforms and smaller actuator-driven builds. It helps you compare mechanical layouts before you download an STL. You can use it to find a project that matches your 3D printer and assembly skills. Polyzon does not confirm whether models are free, their price, license, official status, affiliation, safety or fitness. Check the current terms at the source.
本合集的文字为英文,搜索本身支持任何语言。
 Polyzon合集 · 48个模型 来自5个平台
此合集由Polyzon根据已接入平台的搜索结果整理而成:去除重复项和没有预览图的模型,匹配度低的排在最后,其余按搜索结果顺序排列。模型归作者所有——请在各模型页面查看使用条款。
筛选规则:Polyzon编辑部 · 文字更新于2026年10月10日




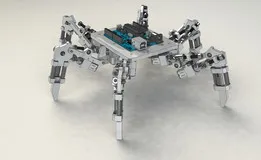



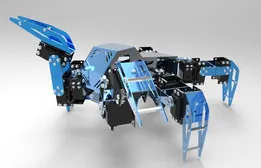





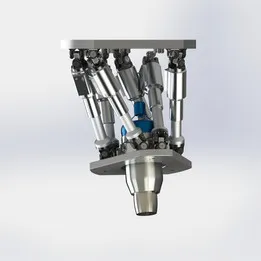


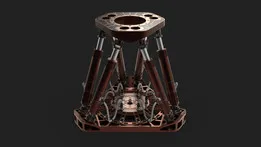


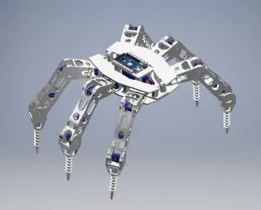
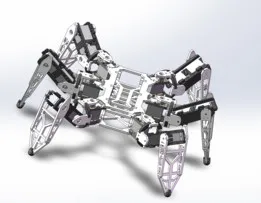
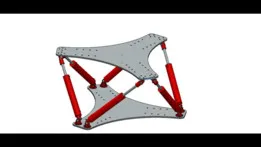


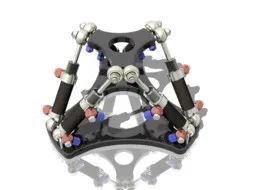
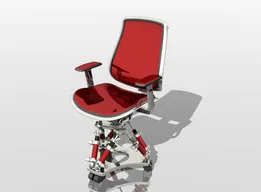
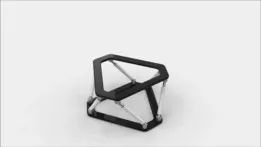


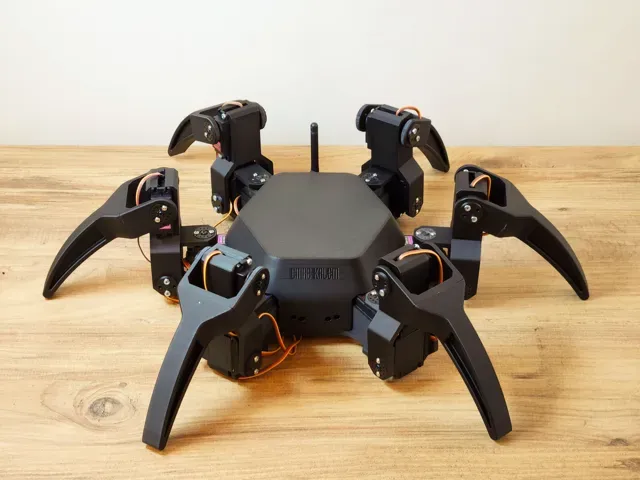
Walking hexapods usually combine a body, six legs and a gait mechanism, while parallel platforms use six linear actuators to move a top plate. RC-controlled and microcontroller-based versions add radio or control electronics, and micro versions shrink the same leg arrangement to a smaller frame. Some models focus on the mechanism alone, while others include mounts and shell parts.
On the author's model page, check the overall size and scale, the number of printed parts and how the legs attach. Look at whether the design expects servos, bearings, screws or rods, and whether supports are needed for the printed geometry. The material and settings listed by the author, along with photos of real prints, can help you judge how the parts will behave on your 3D printer.
To narrow the results, try related terms such as walking robot, spider robot, parallel manipulator, Stewart platform, servo bracket or robot chassis. You can also search by control method, including RC, Arduino or Bluetooth, or by scale, such as micro hexapod or desktop robot. Combining a mechanism term with a part type often brings up builds that match the direction you want.



完整的主题目录:从家居日用到CNC,均可在已接入的来源平台中搜索。