
Бесплатно 
XRP Mecanum Drive / Omnidirectional (fully printed with 2 different frames)
Printables


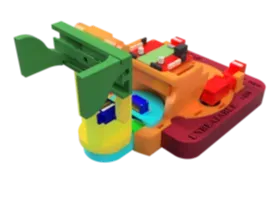
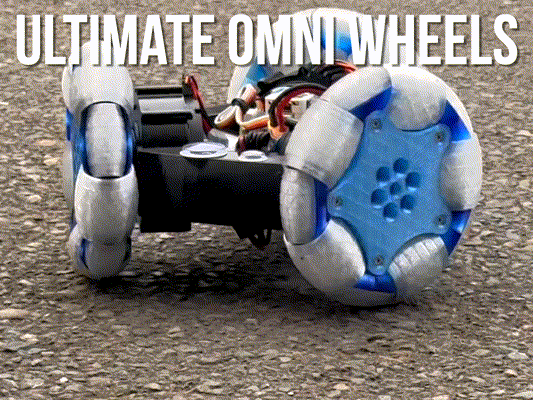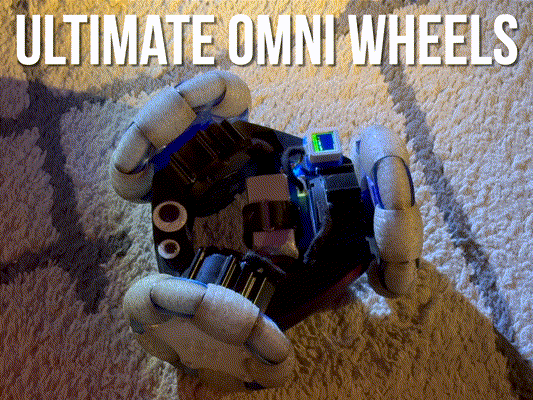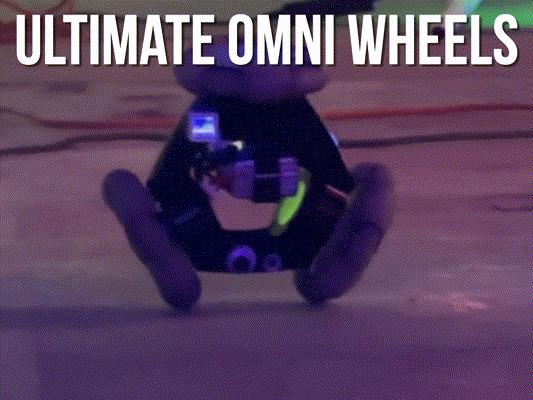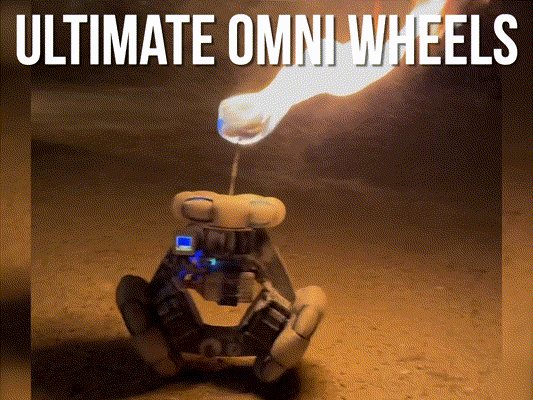
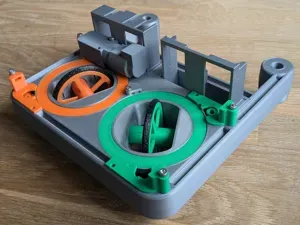
This robot is meant to be an improvement to the existing XRP robot drive base. The robot utilizes three omni-wheels to allow the robot to move in any direction at a time.
By enabling holonomic motion with this drive base provides students learning programming more opportunity to learn about advanced controls.
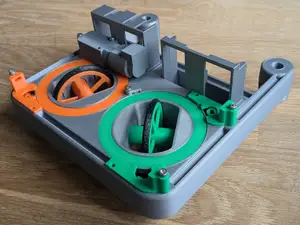
To enable compatibility with the XRP robot ecosystem this robot features the same mounting technique for sensors and other attachable mechanism on each side of the robot. It also uses the same motors, batteries, and control system found in the XRP robot.
Hardware
The omni wheels are assembled with eight 40mm long M3 screws and eight printed rollers. The robot contains much of the same hardware featured in the XRP robot kit. To drive each of the wheels the robot uses motors with integrated encoders.
Print Settings
The chassis and battery cover can be printed without supports, but the omni-wheel shell needs supports. I recommend printing in PLA or PETG with 20% infill density.




Названия используются только для указания источника результата. Polyzon не аффилирован с перечисленными площадками.
Комментарии