免费 
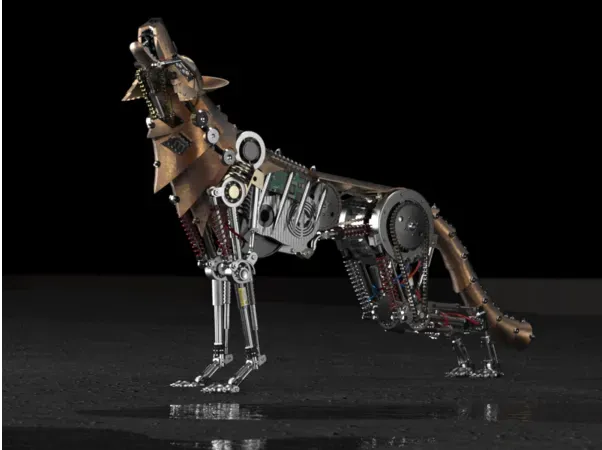
Mechanical Robot Bee
Thingiverse
This collection gathers 3D printing files for mechanical robots: articulated hands and arms, walking automatons, steampunk figures and the gears, bearings and frames that drive them. It is useful when you want a model with moving joints or linkages rather than a static figure. Most entries are STL files meant for a desktop 3D printer, with assembly notes on the author's page. Polyzon does not confirm whether models are free, their price, license, official status, affiliation, safety or fitness. Check the current terms at the source.
本合集的文字为英文,搜索本身支持任何语言。
 Polyzon合集 · 47个模型 来自4个平台
此合集由Polyzon根据已接入平台的搜索结果整理而成:去除重复项和没有预览图的模型,匹配度低的排在最后,其余按搜索结果顺序排列。模型归作者所有——请在各模型页面查看使用条款。
筛选规则:Polyzon编辑部 · 文字更新于2026年10月14日


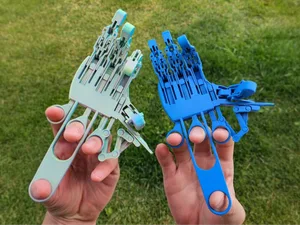


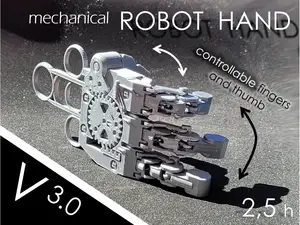


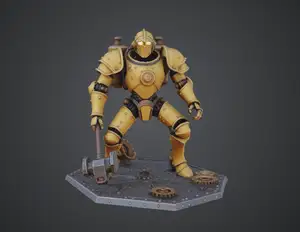
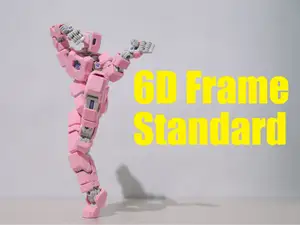


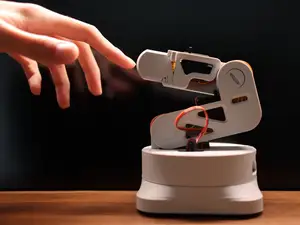


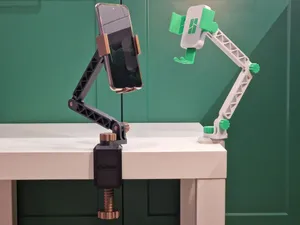


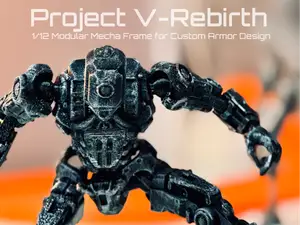


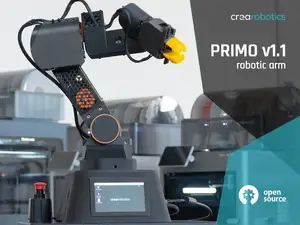


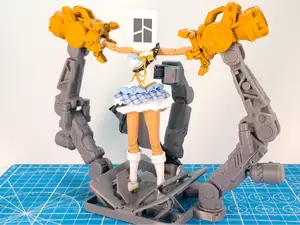


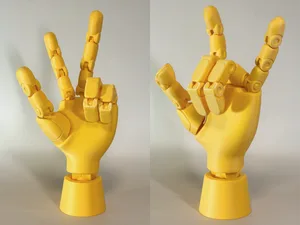


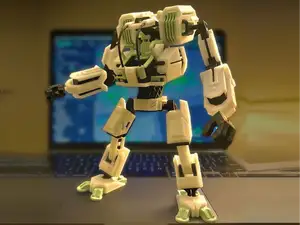


The kinds differ mainly in what moves. Hands and arms rely on finger segments, joints and tendon or servo routing, so their part count is high and assembly is the main task. Walking automatons and clockwork figures depend on leg linkage geometry and balance, and often include a crank or motor mount. Steampunk robots add decorative gears, pipes and plates that are usually printed as separate pieces and glued or pinned together.
When choosing, open the author's page and read the size and scale, the number of parts, and whether supports are needed. For anything that moves, check the stated clearances, pin diameters and tolerances, and whether fasteners, bearings or servos are required. Look at the material and settings the author lists, and at photos of real prints, since wall thickness and orientation affect how joints behave.
To narrow the results, try synonyms such as automaton, articulated hand, exoskeleton arm, clockwork figure or walking toy, and combine them with a scale or purpose. Related searches help too: servo brackets, gearboxes, bearings, printer frames and desk stands appear in the same family of models. If you already have a mechanism in mind, search for the specific part name instead of the general topic.
Mechanical models are usually printed in several parts, so plan the assembly order before starting. Test-fit pins and axles on a small piece first, and keep in mind that scaling a model up or down changes every clearance at once.




完整的主题目录:从家居日用到CNC,均可在已接入的来源平台中搜索。