
無料 
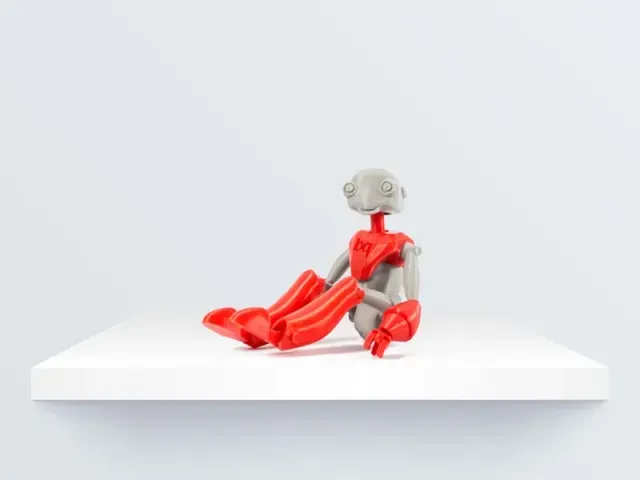
BeQui, Jointed Robot
Pinshape
This collection gathers STL files for jointed robots: tiny print-in-place figures, multi-joint arms, hexapods and walking machines. It helps you compare how the joints are built before you send a model to your 3D printer. The range covers both simple posable figures and mechanisms with many separate parts. Polyzon does not confirm whether models are free, their price, license, official status, affiliation, safety or fitness. Check the current terms at the source.
このコレクションの本文は英語で書かれています。検索自体はどの言語でも使えます。
 Polyzonのコレクション · モデル47件 8サイトから収集
このコレクションは、Polyzonが対応サイトの検索結果をもとに作成しています。重複やプレビューのないモデルは除外し、関連性の低いものは後ろに回し、それ以外は検索結果の順に並べています。モデルの権利は各作者にあります。利用条件は各モデルのページでご確認ください。
選定基準:Polyzon編集部 · 本文の更新日:2026年10月13日




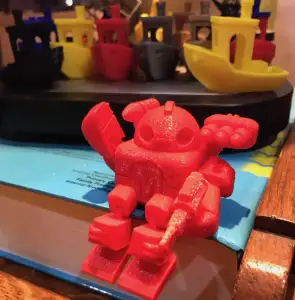
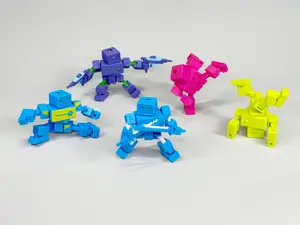
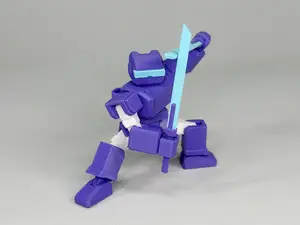
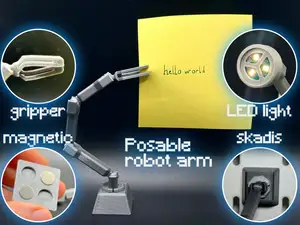
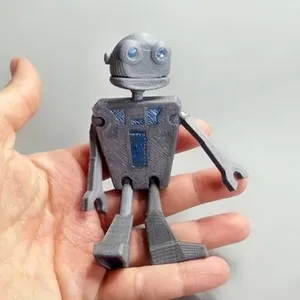

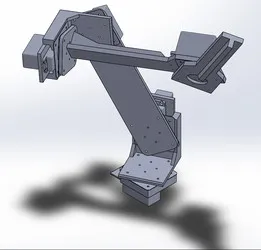
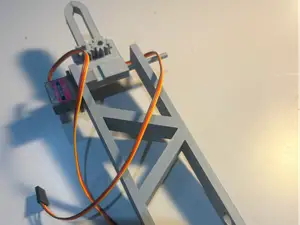





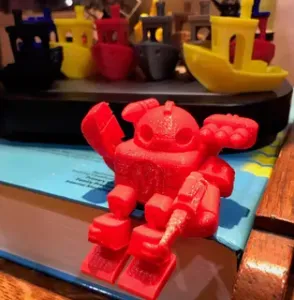

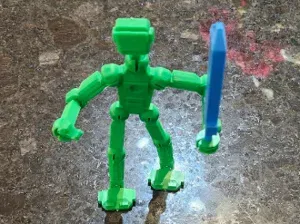




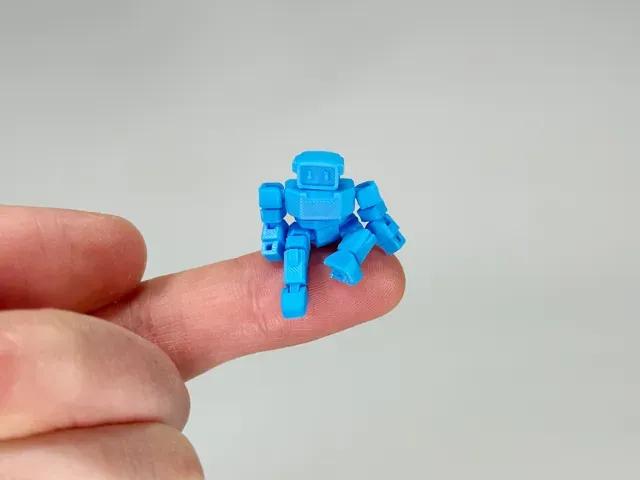
Jointed robot models often fall into a few groups: print-in-place figures with enclosed hinges, robot arms with a small number of large joints, and hexapod or walking platforms that use several legs. Print-in-place designs arrive as one piece and rely on clearances between parts, while arm and hexapod builds may include separate links, pins or servo mounts. Some files focus on a single joint mechanism, such as a ball joint or a hinge that uses filament as a pin.
On the author's model page, check the stated size and scale, the number of parts, and whether the design needs supports or assembly. Look at the photos of real prints to see how the joints move and where the clearances sit. For print-in-place parts, layer height, horizontal expansion and cooling settings matter because they affect how the hinges move. If the model uses servos or magnets, confirm the hardware dimensions before printing.
To refine a search, try synonyms such as articulated, posable, print-in-place, ball-jointed or multi-joint, and combine them with robot arm, hexapod or walking robot. Related topics include robot joints, hinge mechanisms, servo brackets and magnetic mounts. Adding terms like tiny, modular or parametric can narrow results toward a particular build style.


暮らし・日用品からCNCまで、すべてのテーマをそろえたカタログ。対応サイトを横断して検索できます。