
免费 
BeQui, Jointed Robot
Pinshape
This collection gathers STL files for jointed robots: tiny print-in-place figures, multi-joint arms, hexapods and walking machines. It helps you compare how the joints are built before you send a model to your 3D printer. The range covers both simple posable figures and mechanisms with many separate parts. Polyzon does not confirm whether models are free, their price, license, official status, affiliation, safety or fitness. Check the current terms at the source.
本合集的文字为英文,搜索本身支持任何语言。
 Polyzon合集 · 47个模型 来自8个平台
此合集由Polyzon根据已接入平台的搜索结果整理而成:去除重复项和没有预览图的模型,匹配度低的排在最后,其余按搜索结果顺序排列。模型归作者所有——请在各模型页面查看使用条款。
筛选规则:Polyzon编辑部 · 文字更新于2026年10月13日




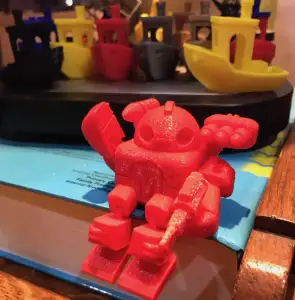
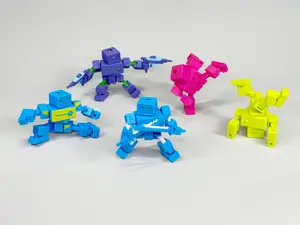
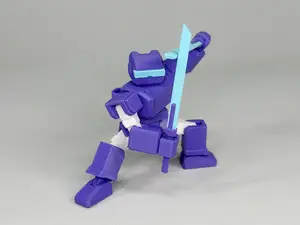
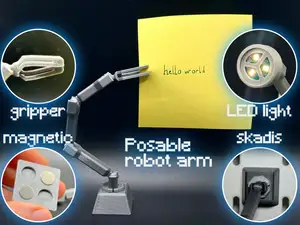
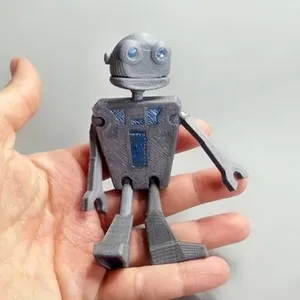

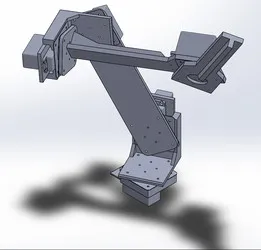
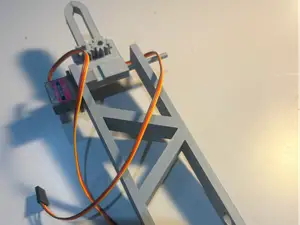
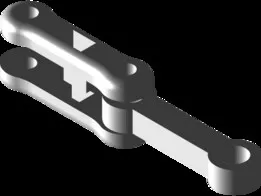

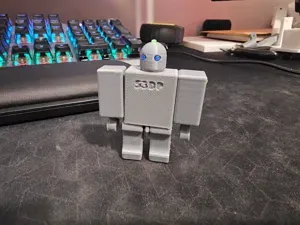
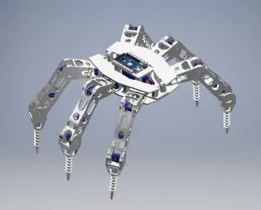




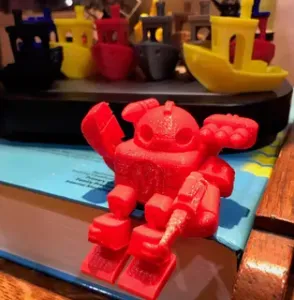

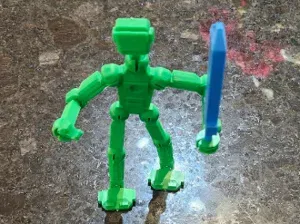
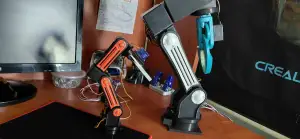




Jointed robot models often fall into a few groups: print-in-place figures with enclosed hinges, robot arms with a small number of large joints, and hexapod or walking platforms that use several legs. Print-in-place designs arrive as one piece and rely on clearances between parts, while arm and hexapod builds may include separate links, pins or servo mounts. Some files focus on a single joint mechanism, such as a ball joint or a hinge that uses filament as a pin.
On the author's model page, check the stated size and scale, the number of parts, and whether the design needs supports or assembly. Look at the photos of real prints to see how the joints move and where the clearances sit. For print-in-place parts, layer height, horizontal expansion and cooling settings matter because they affect how the hinges move. If the model uses servos or magnets, confirm the hardware dimensions before printing.
To refine a search, try synonyms such as articulated, posable, print-in-place, ball-jointed or multi-joint, and combine them with robot arm, hexapod or walking robot. Related topics include robot joints, hinge mechanisms, servo brackets and magnetic mounts. Adding terms like tiny, modular or parametric can narrow results toward a particular build style.
完整的主题目录:从家居日用到CNC,均可在已接入的来源平台中搜索。